Skip to content
Android waitlistTry on iPad
Get started

Programmable devices and control: OCR A‑Level Design Engineering questions

OCR A-Level Design Engineering past-paper questions on 6.5 Programmable devices and control, 2021–2025, with mark schemes and examiner’s reports where available.

Past paper difficulty
Paper
All papers
Exam
All years

Loading the full question list…

193 questions

  1. Q4(d)

    June 2025 · H404/01 · ★★★★

    The whole paper ↗
    1
    Setup for original question 4(d)

    Loading the question setup…

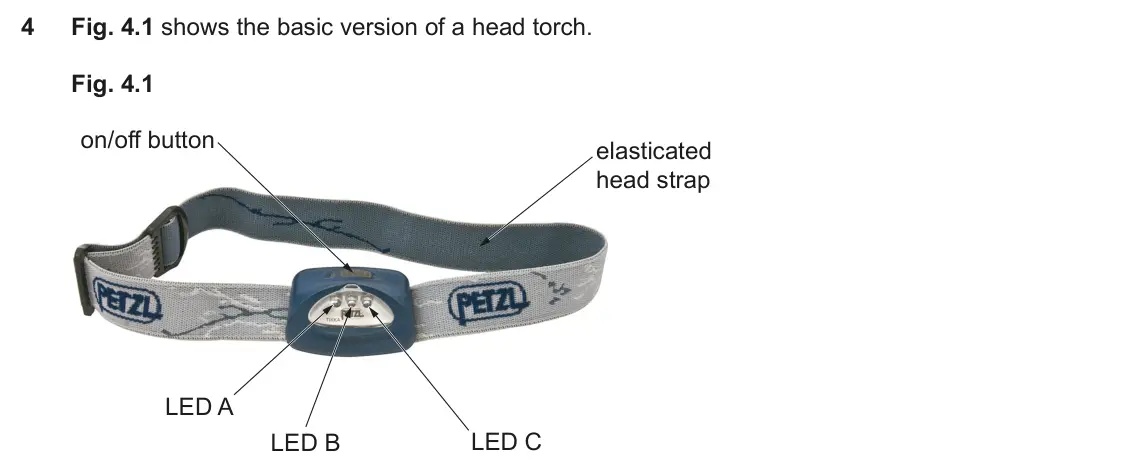
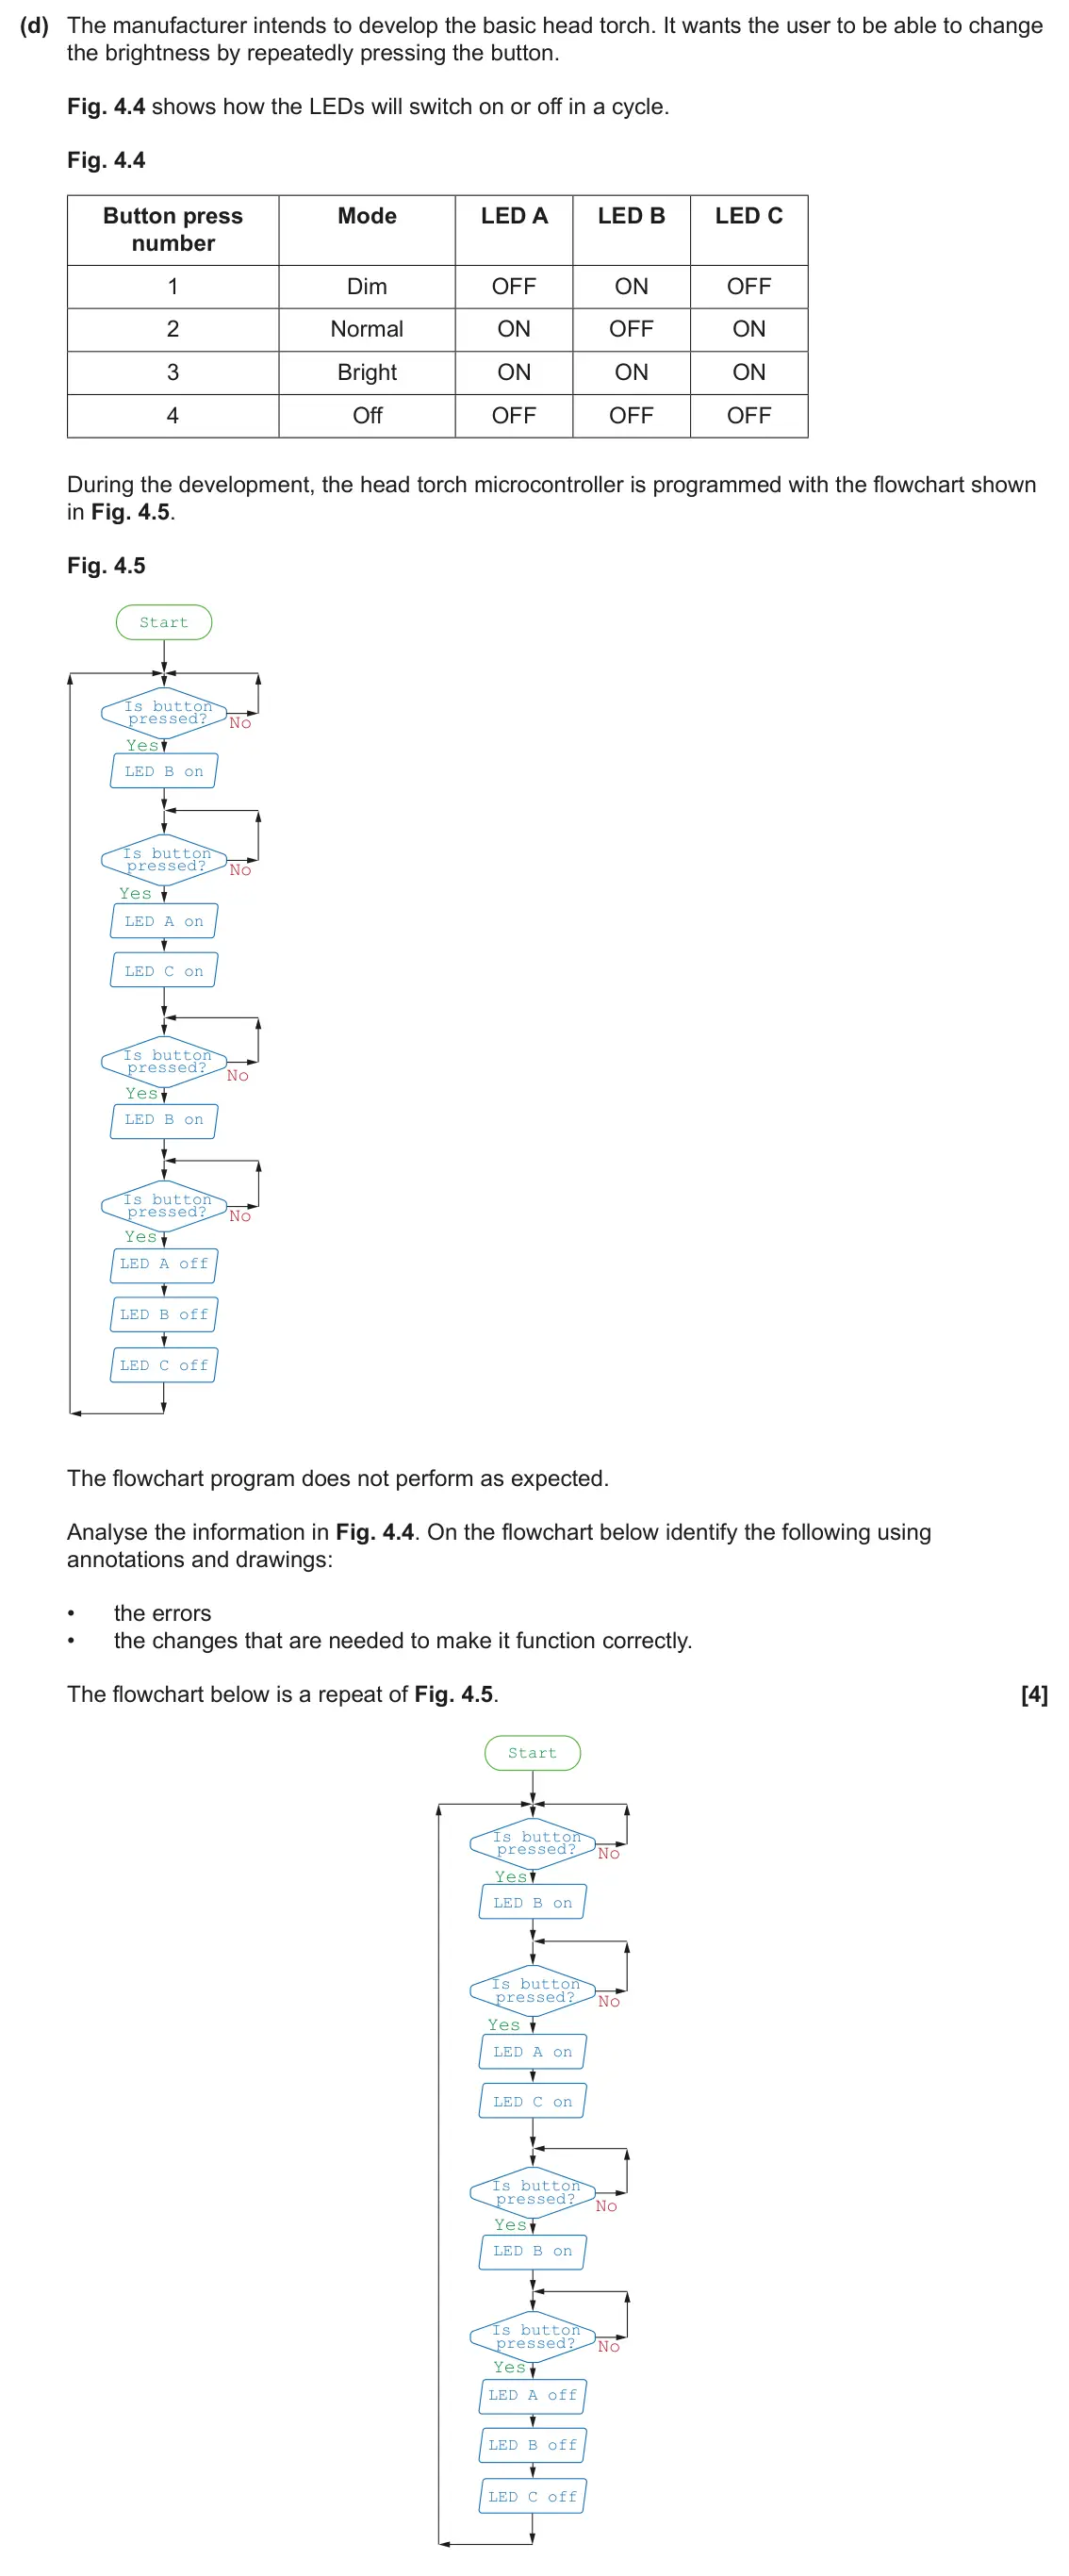
    Original question 4(d): The manufacturer intends to develop the basic head torch. It wants the user to be able to change the brightness by repeatedly pressing the button. Fig. 4.4 show

    Loading the question…

  2. Q4

    June 2025 · H404/02 · ★★★★★

    Sources (insert) ↗
    The whole paper ↗
    2
    Setup for original question 4

    Loading the question setup…

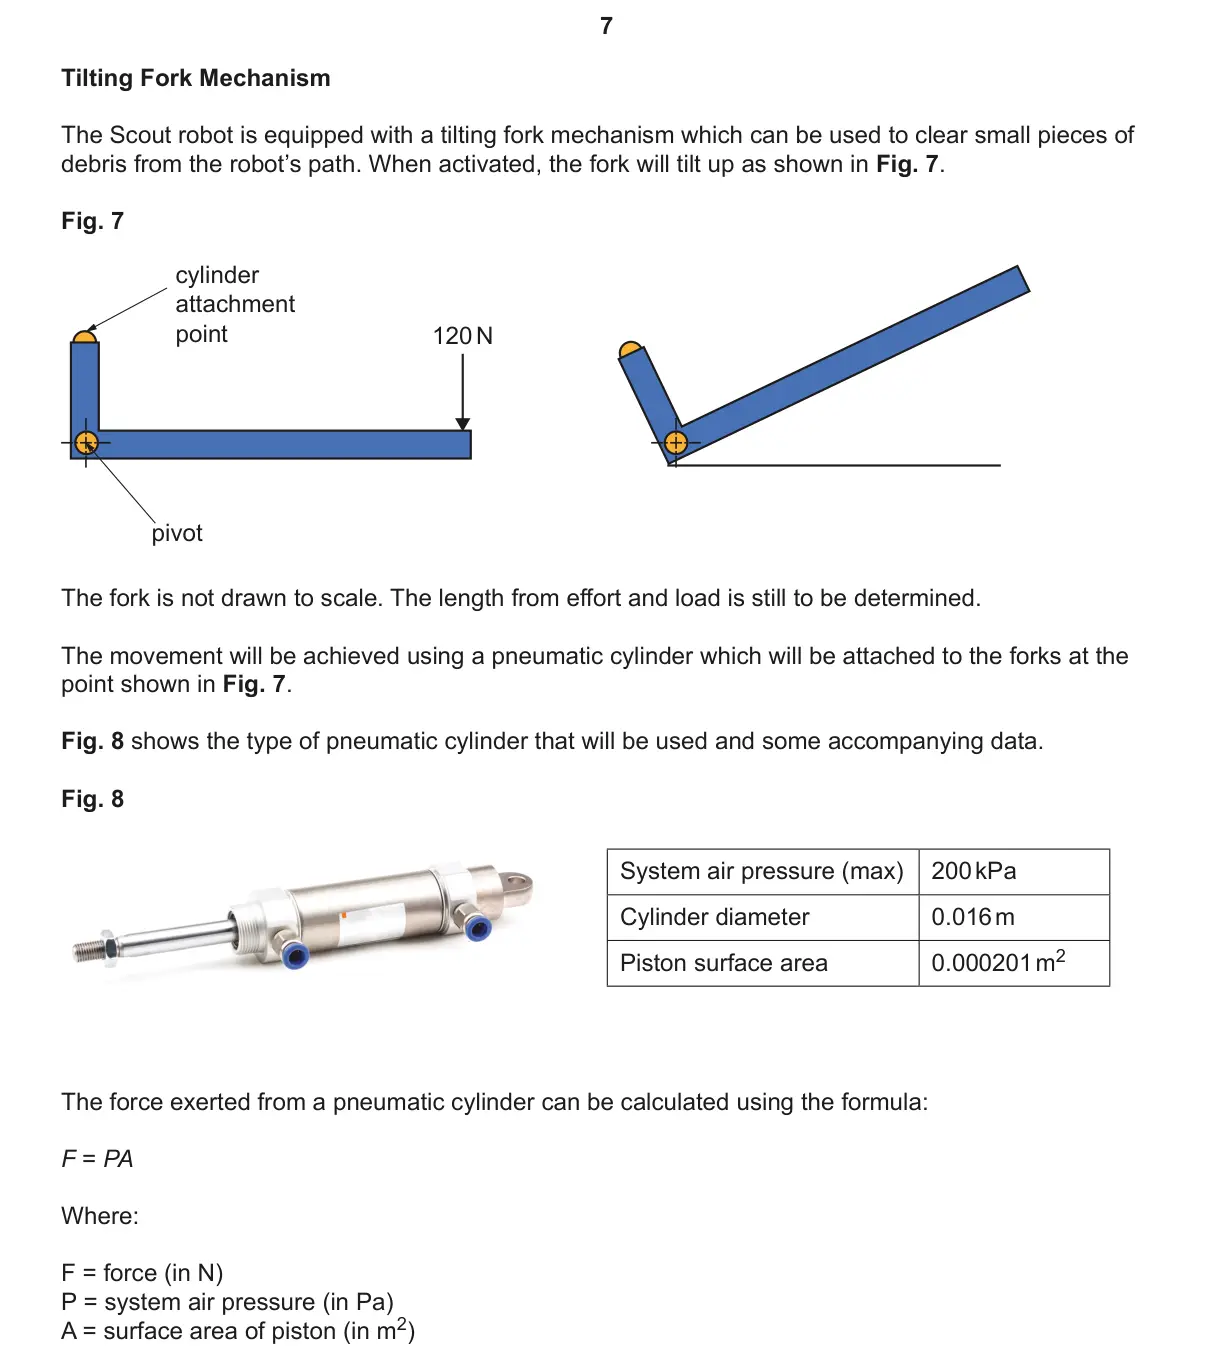
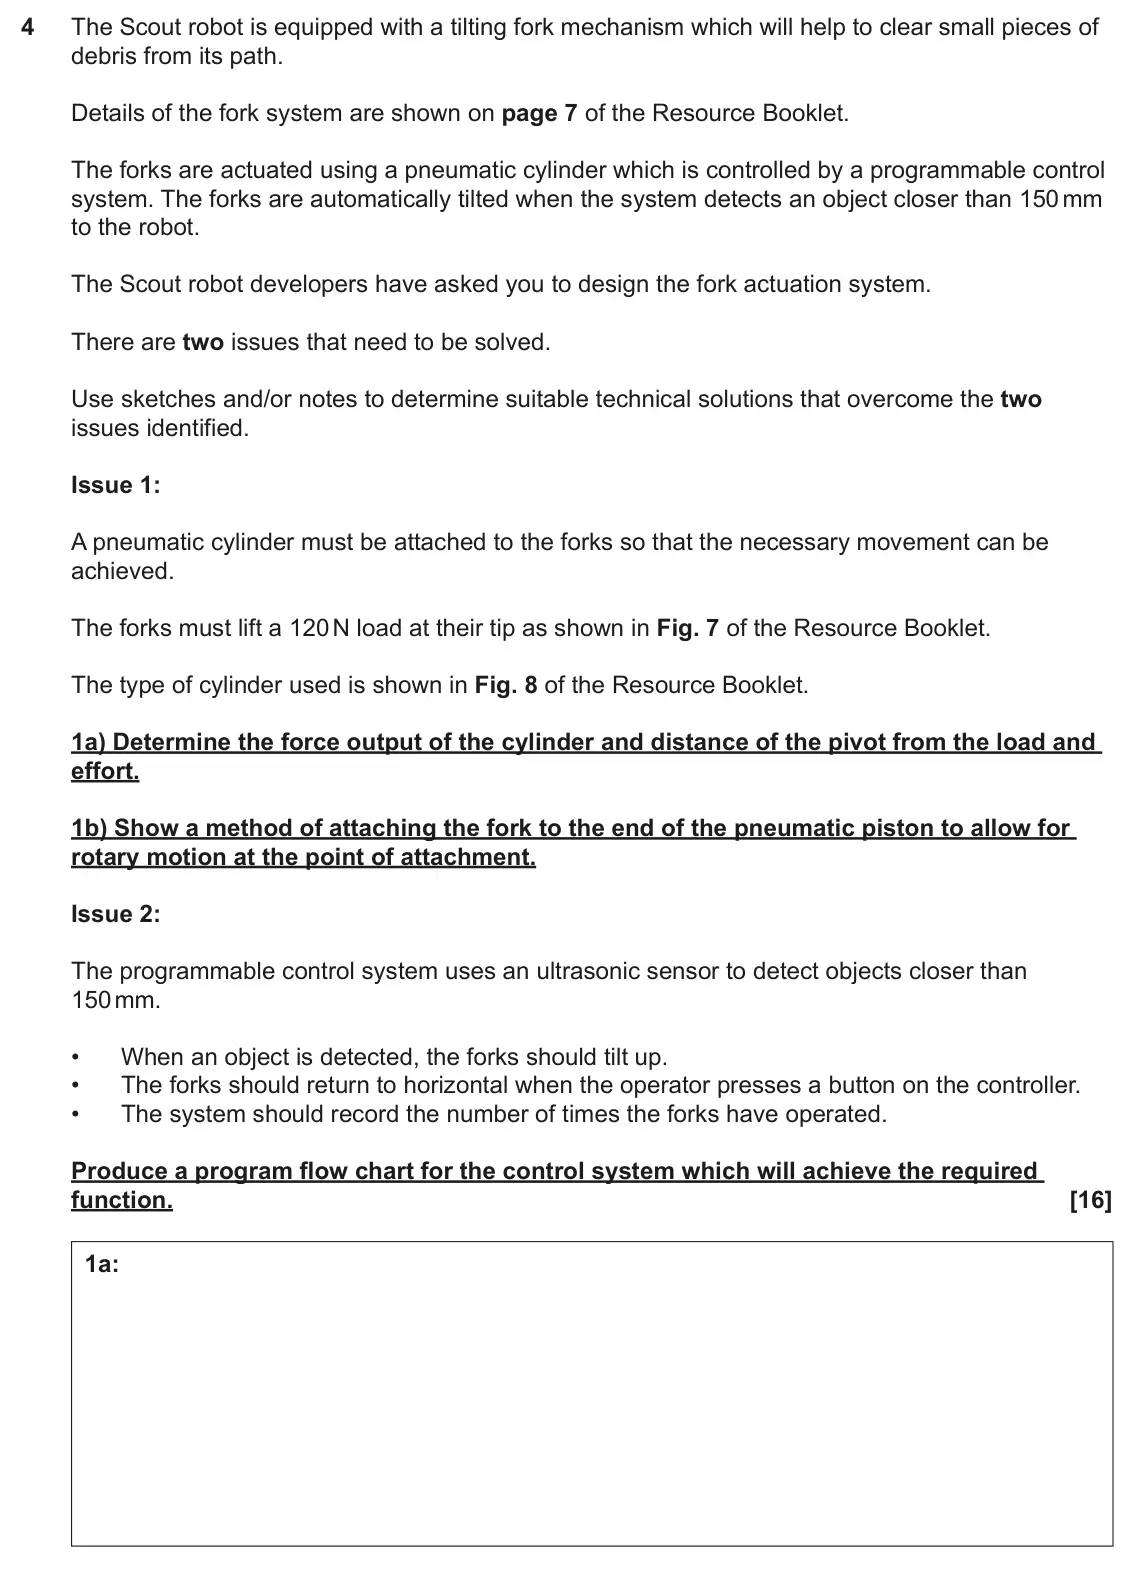
    Original question 4: The Scout robot is equipped with a tilting fork mechanism which will help to clear small pieces of debris from its path. Details of the fork system are shown on

    Loading the question…

  3. Q4(c)(i)

    June 2024 · H404/01 · ★★

    The whole paper ↗
    3
    Setup for original question 4(c)(i)

    Loading the question setup…

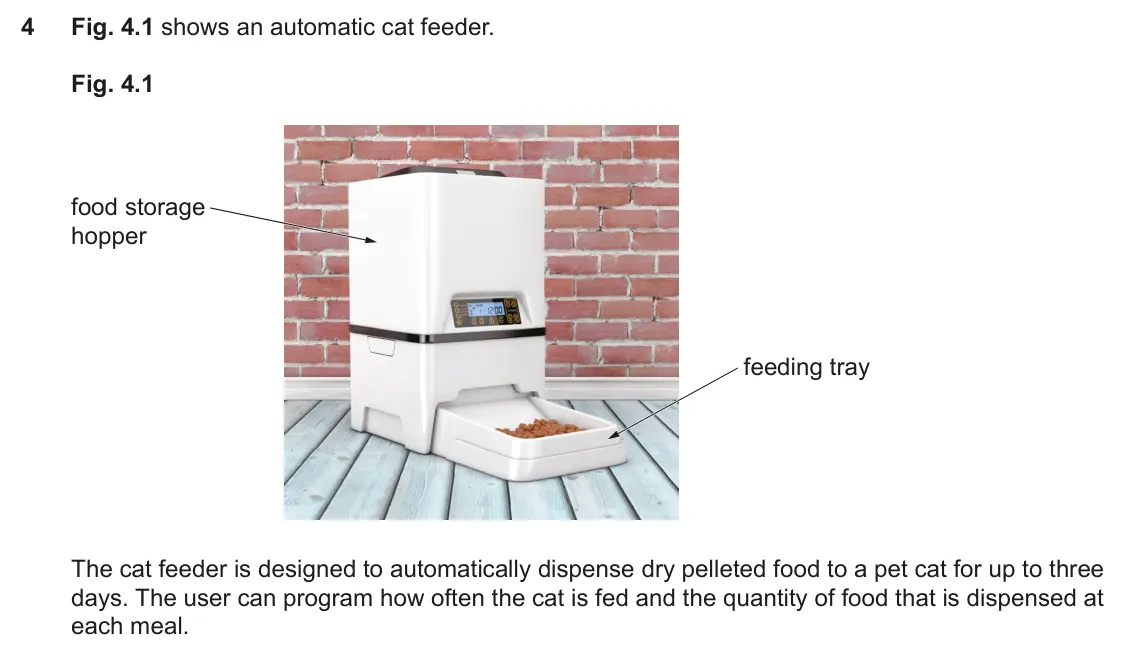
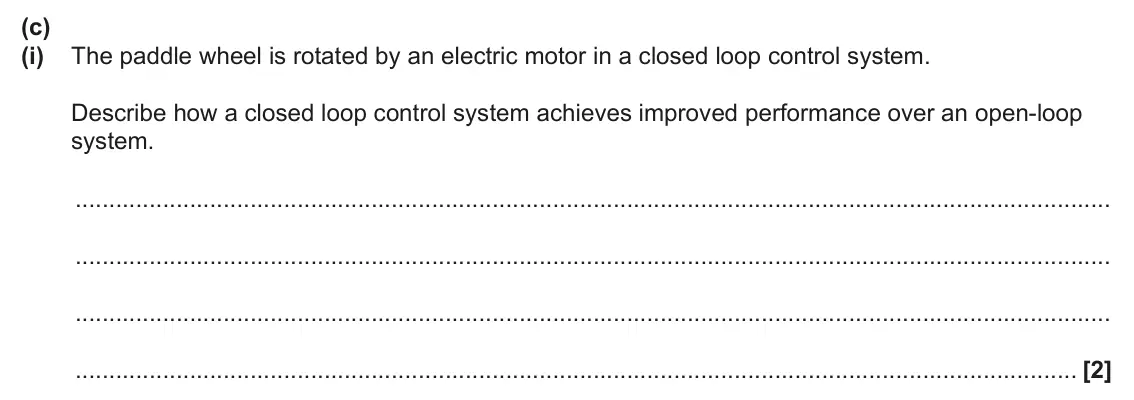
    Original question 4(c)(i): The paddle wheel is rotated by an electric motor in a closed loop control system. Describe how a closed loop control system achieves improved performance over a

    Loading the question…

  4. Q4

    June 2024 · H404/02 · ★★★★★

    Sources (insert) ↗
    The whole paper ↗
    4
    Setup for original question 4

    Loading the question setup…

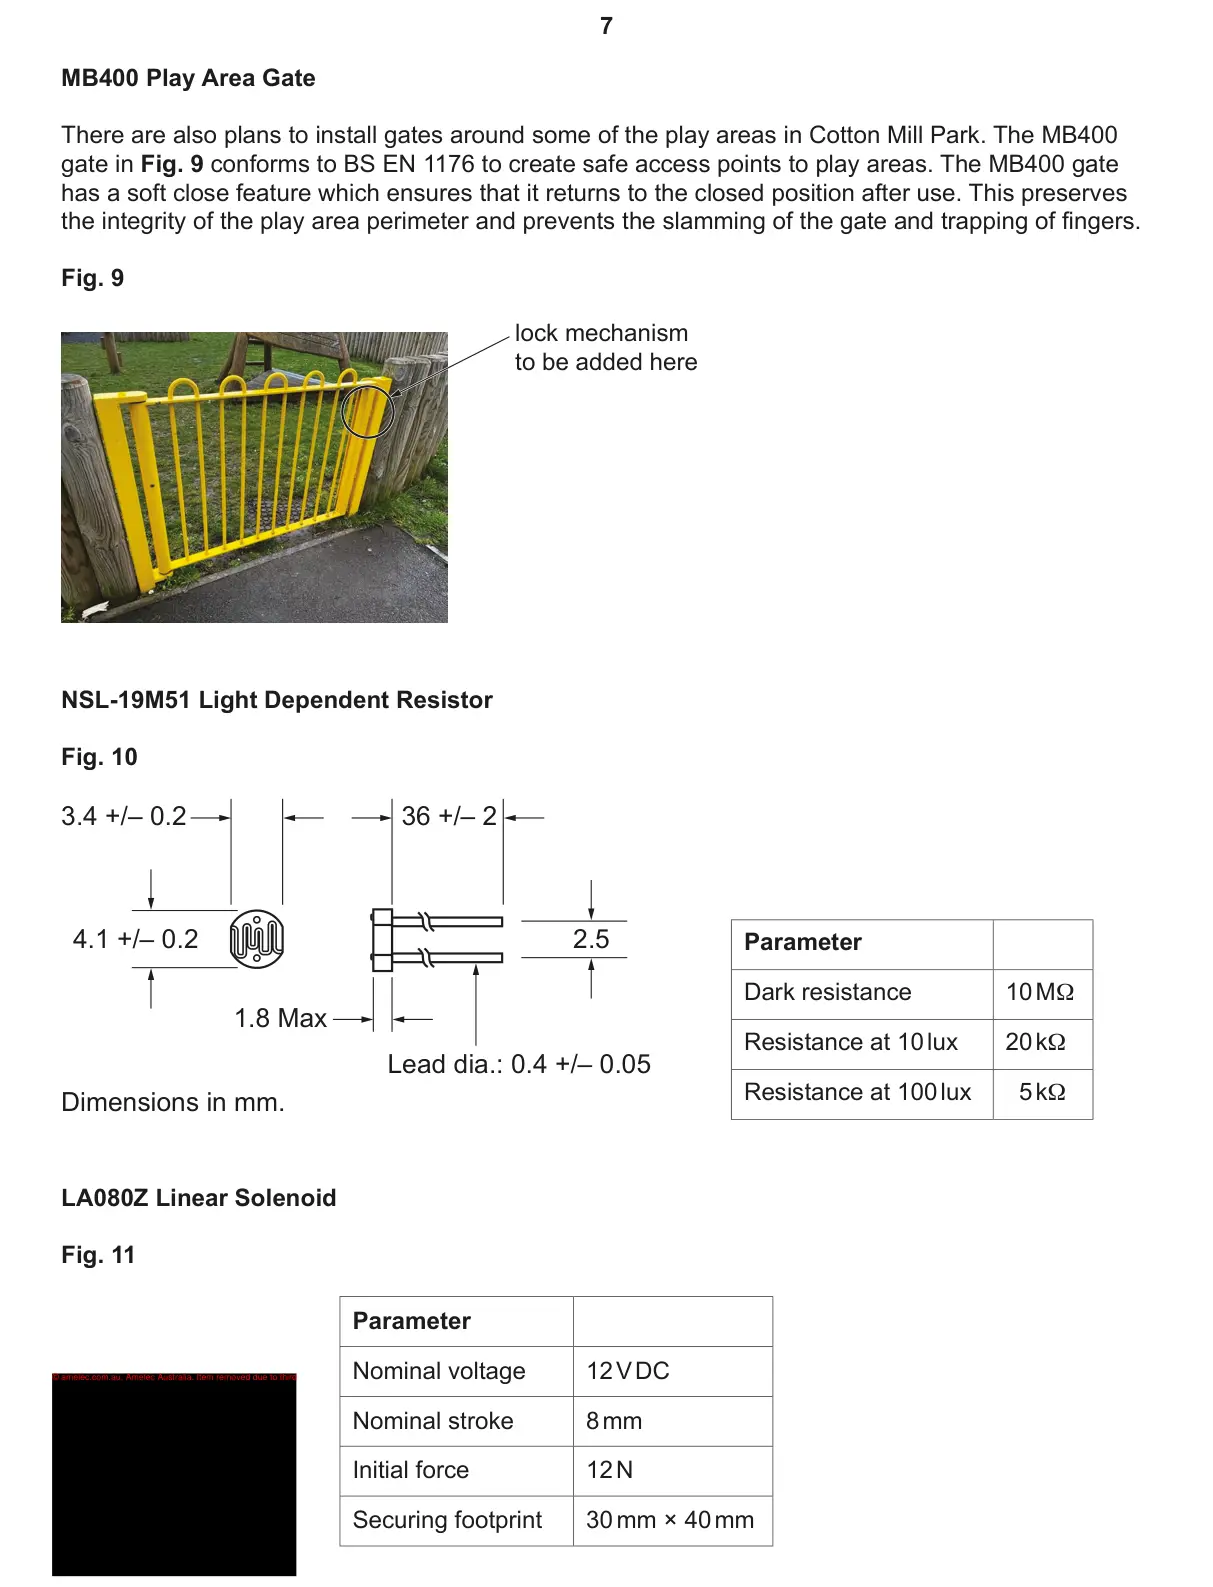
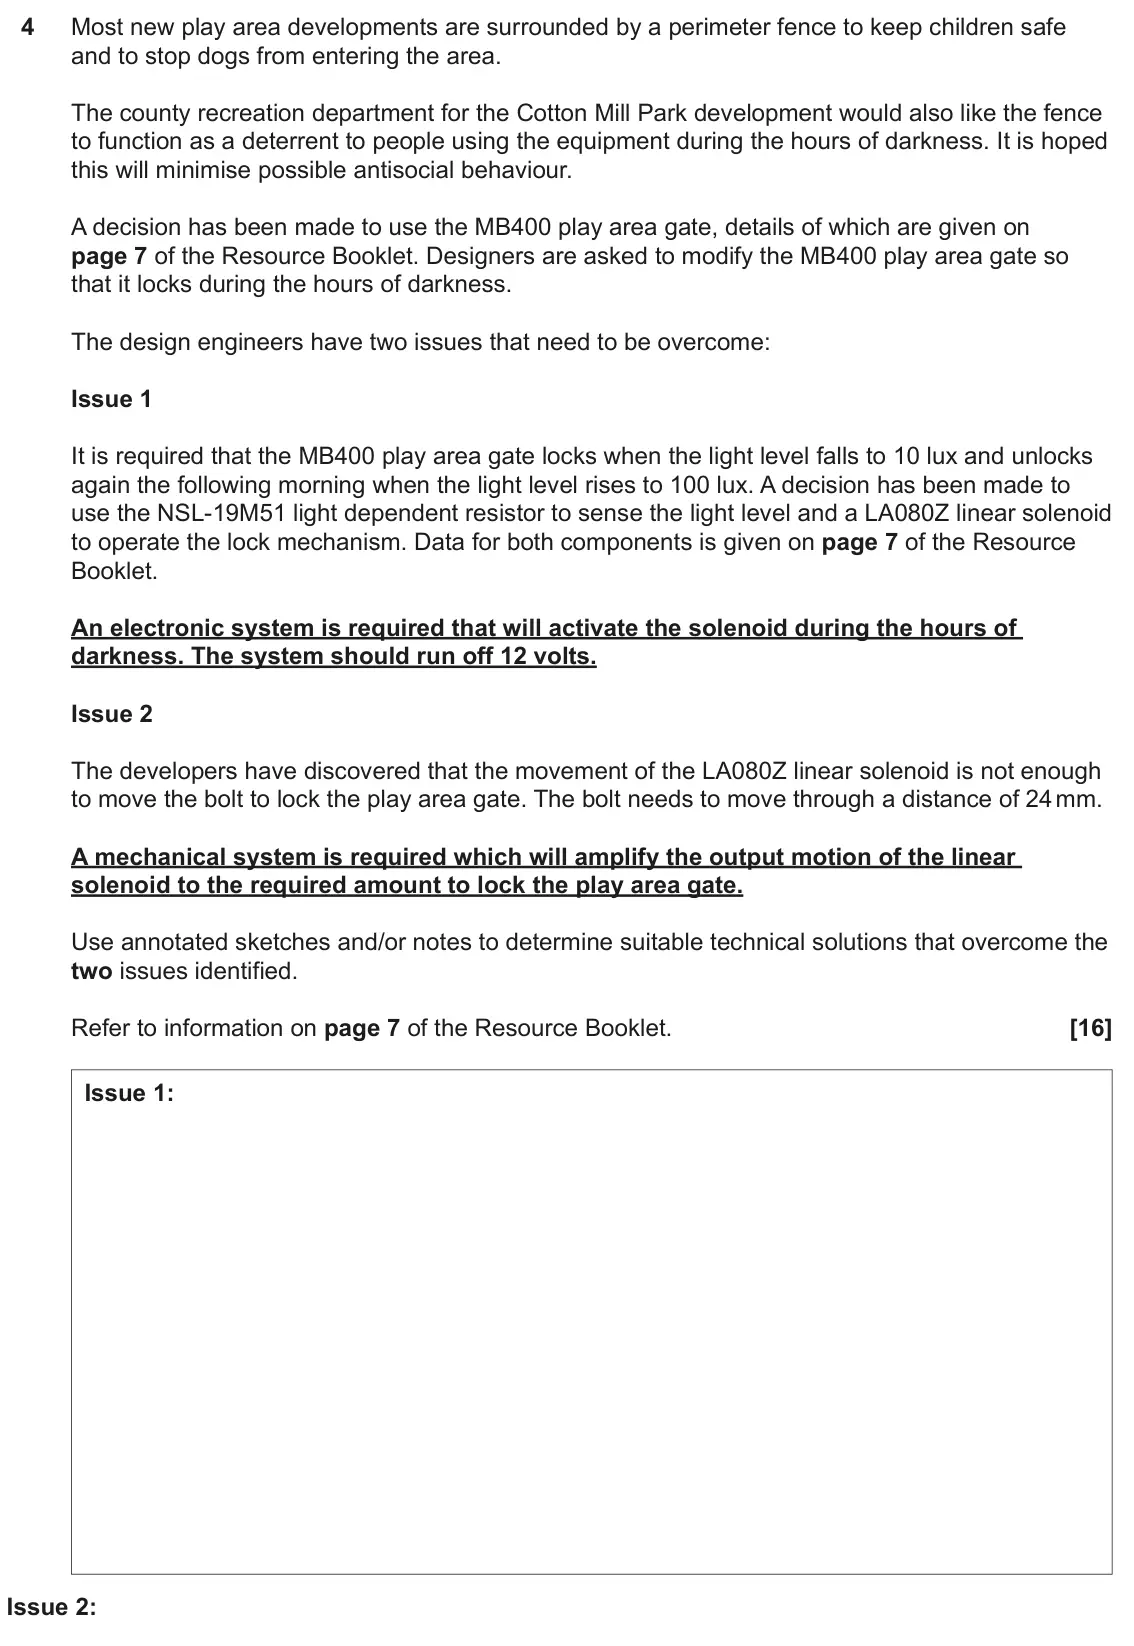
    Original question 4: Most new play area developments are surrounded by a perimeter fence to keep children safe and to stop dogs from entering the area. The county recreation departm

    Loading the question…

  5. Q1(d)(v)

    June 2023 · H404/01 · ★★

    The whole paper ↗
    5
    Setup for original question 1(d)(v)

    Loading the question setup…

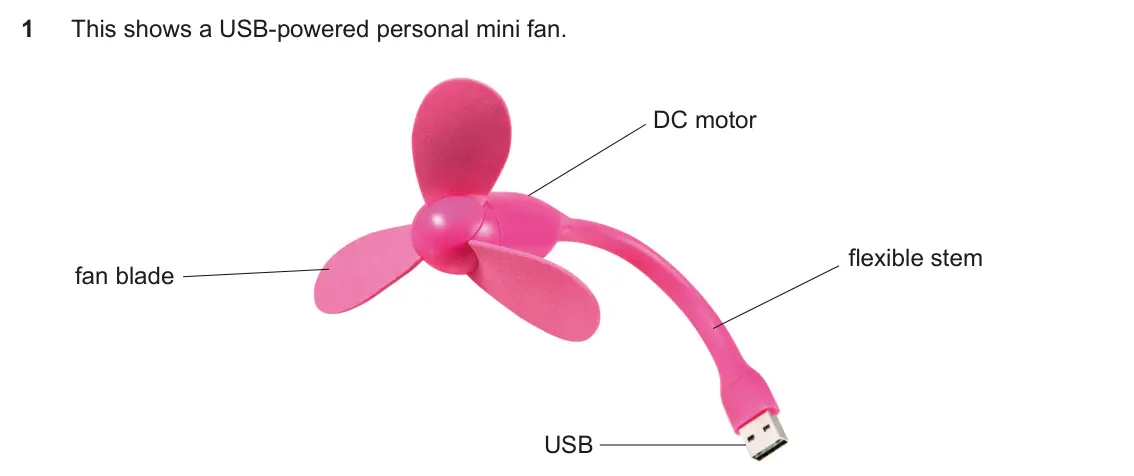
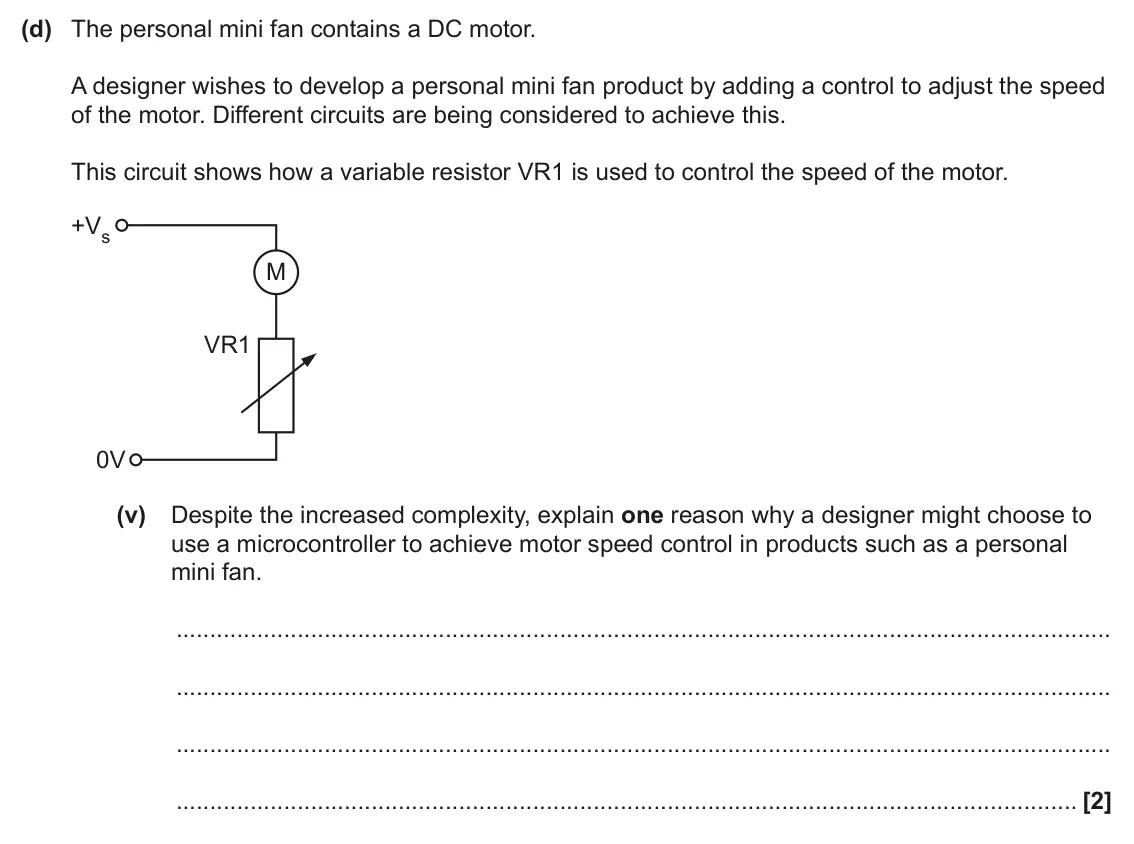
    Original question 1(d)(v): Despite the increased complexity, explain one reason why a designer might choose to use a microcontroller to achieve motor speed control in products such as a p

    Loading the question…

  6. Q4(a)

    June 2023 · H404/01 · ★★

    The whole paper ↗
    6
    Setup for original question 4(a)

    Loading the question setup…

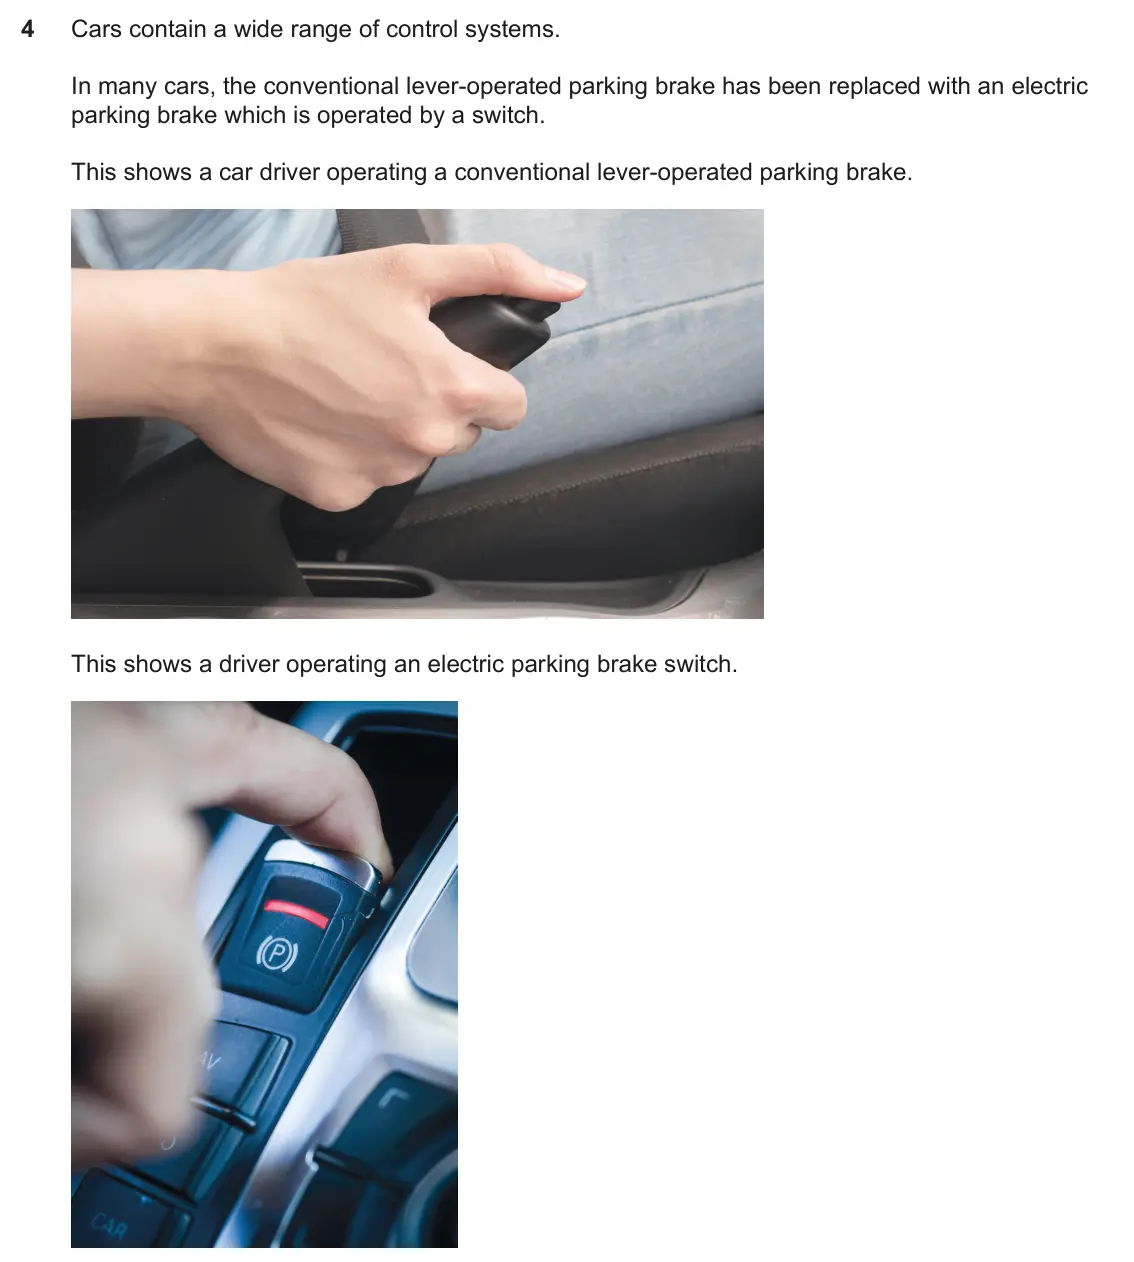
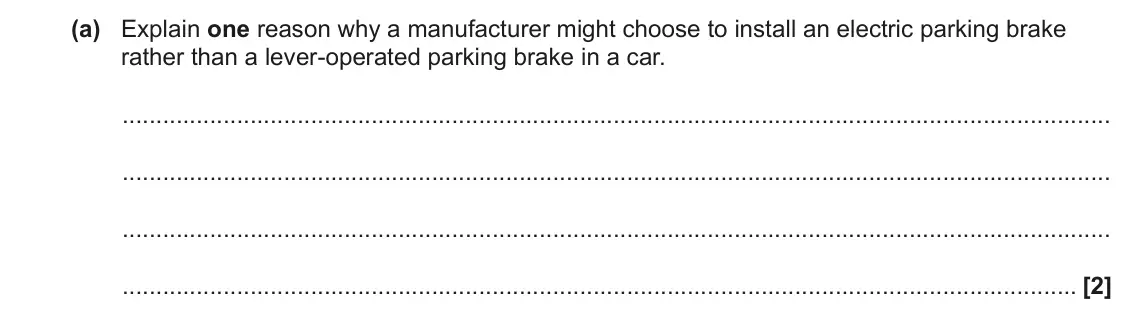
    Original question 4(a): Explain one reason why a manufacturer might choose to install an electric parking brake rather than a lever-operated parking brake in a car. [2]

    Loading the question…

  7. Q4(c)(i)

    June 2023 · H404/01 · ★★★

    The whole paper ↗
    7
    Setup for original question 4(c)(i)

    Loading the question setup…

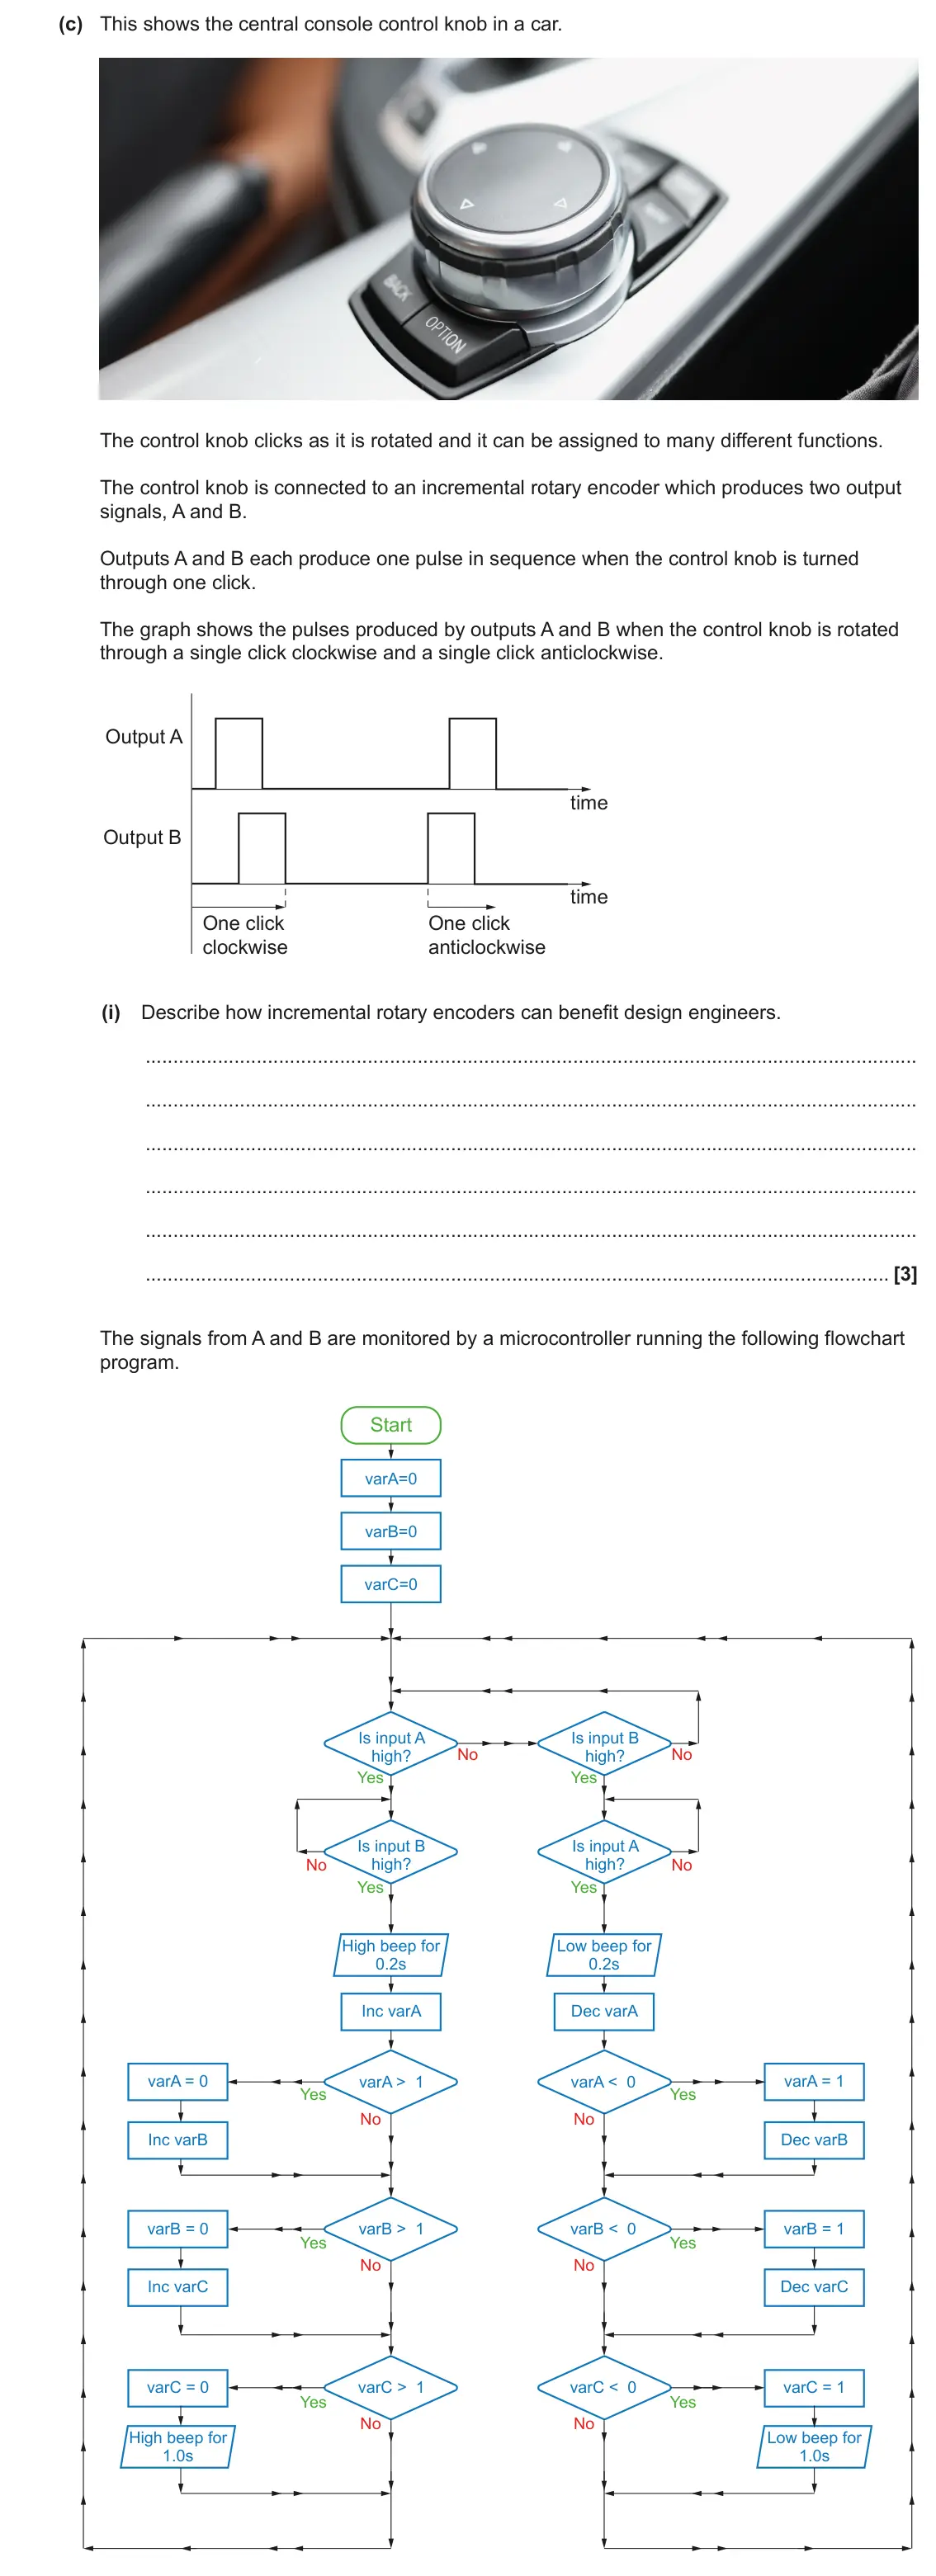
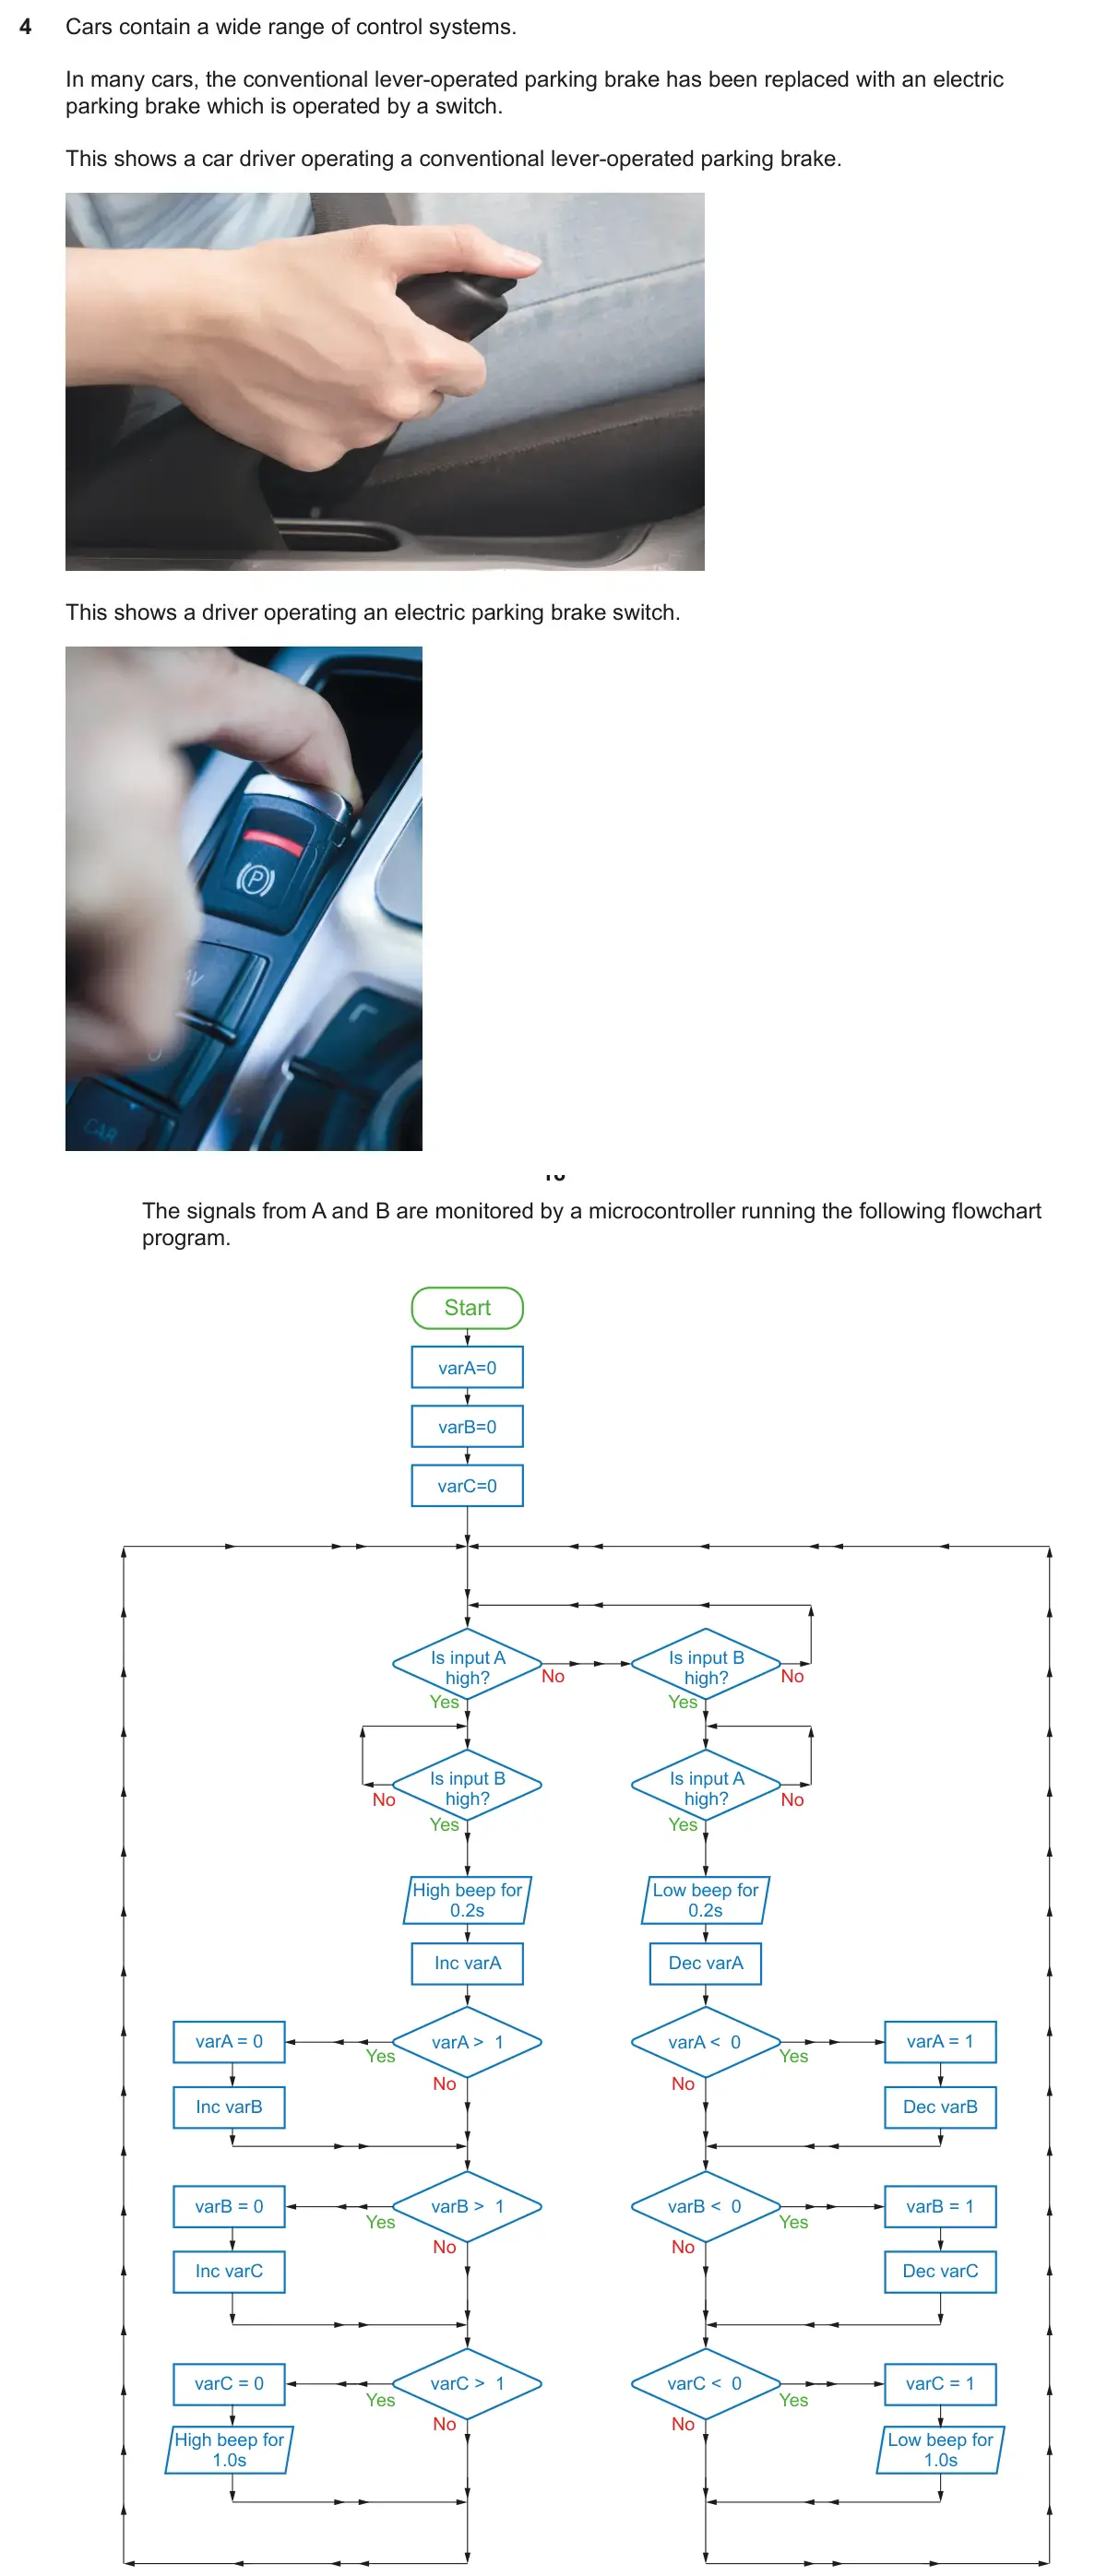
    Original question 4(c)(i): Describe how incremental rotary encoders can benefit design engineers. [3] The signals from A and B are monitored by a microcontroller running the following flo

    Loading the question…

  8. Q4(c)(ii)

    June 2023 · H404/01 · ★★★★

    The whole paper ↗
    8
    Setup for original question 4(c)(ii)

    Loading the question setup…

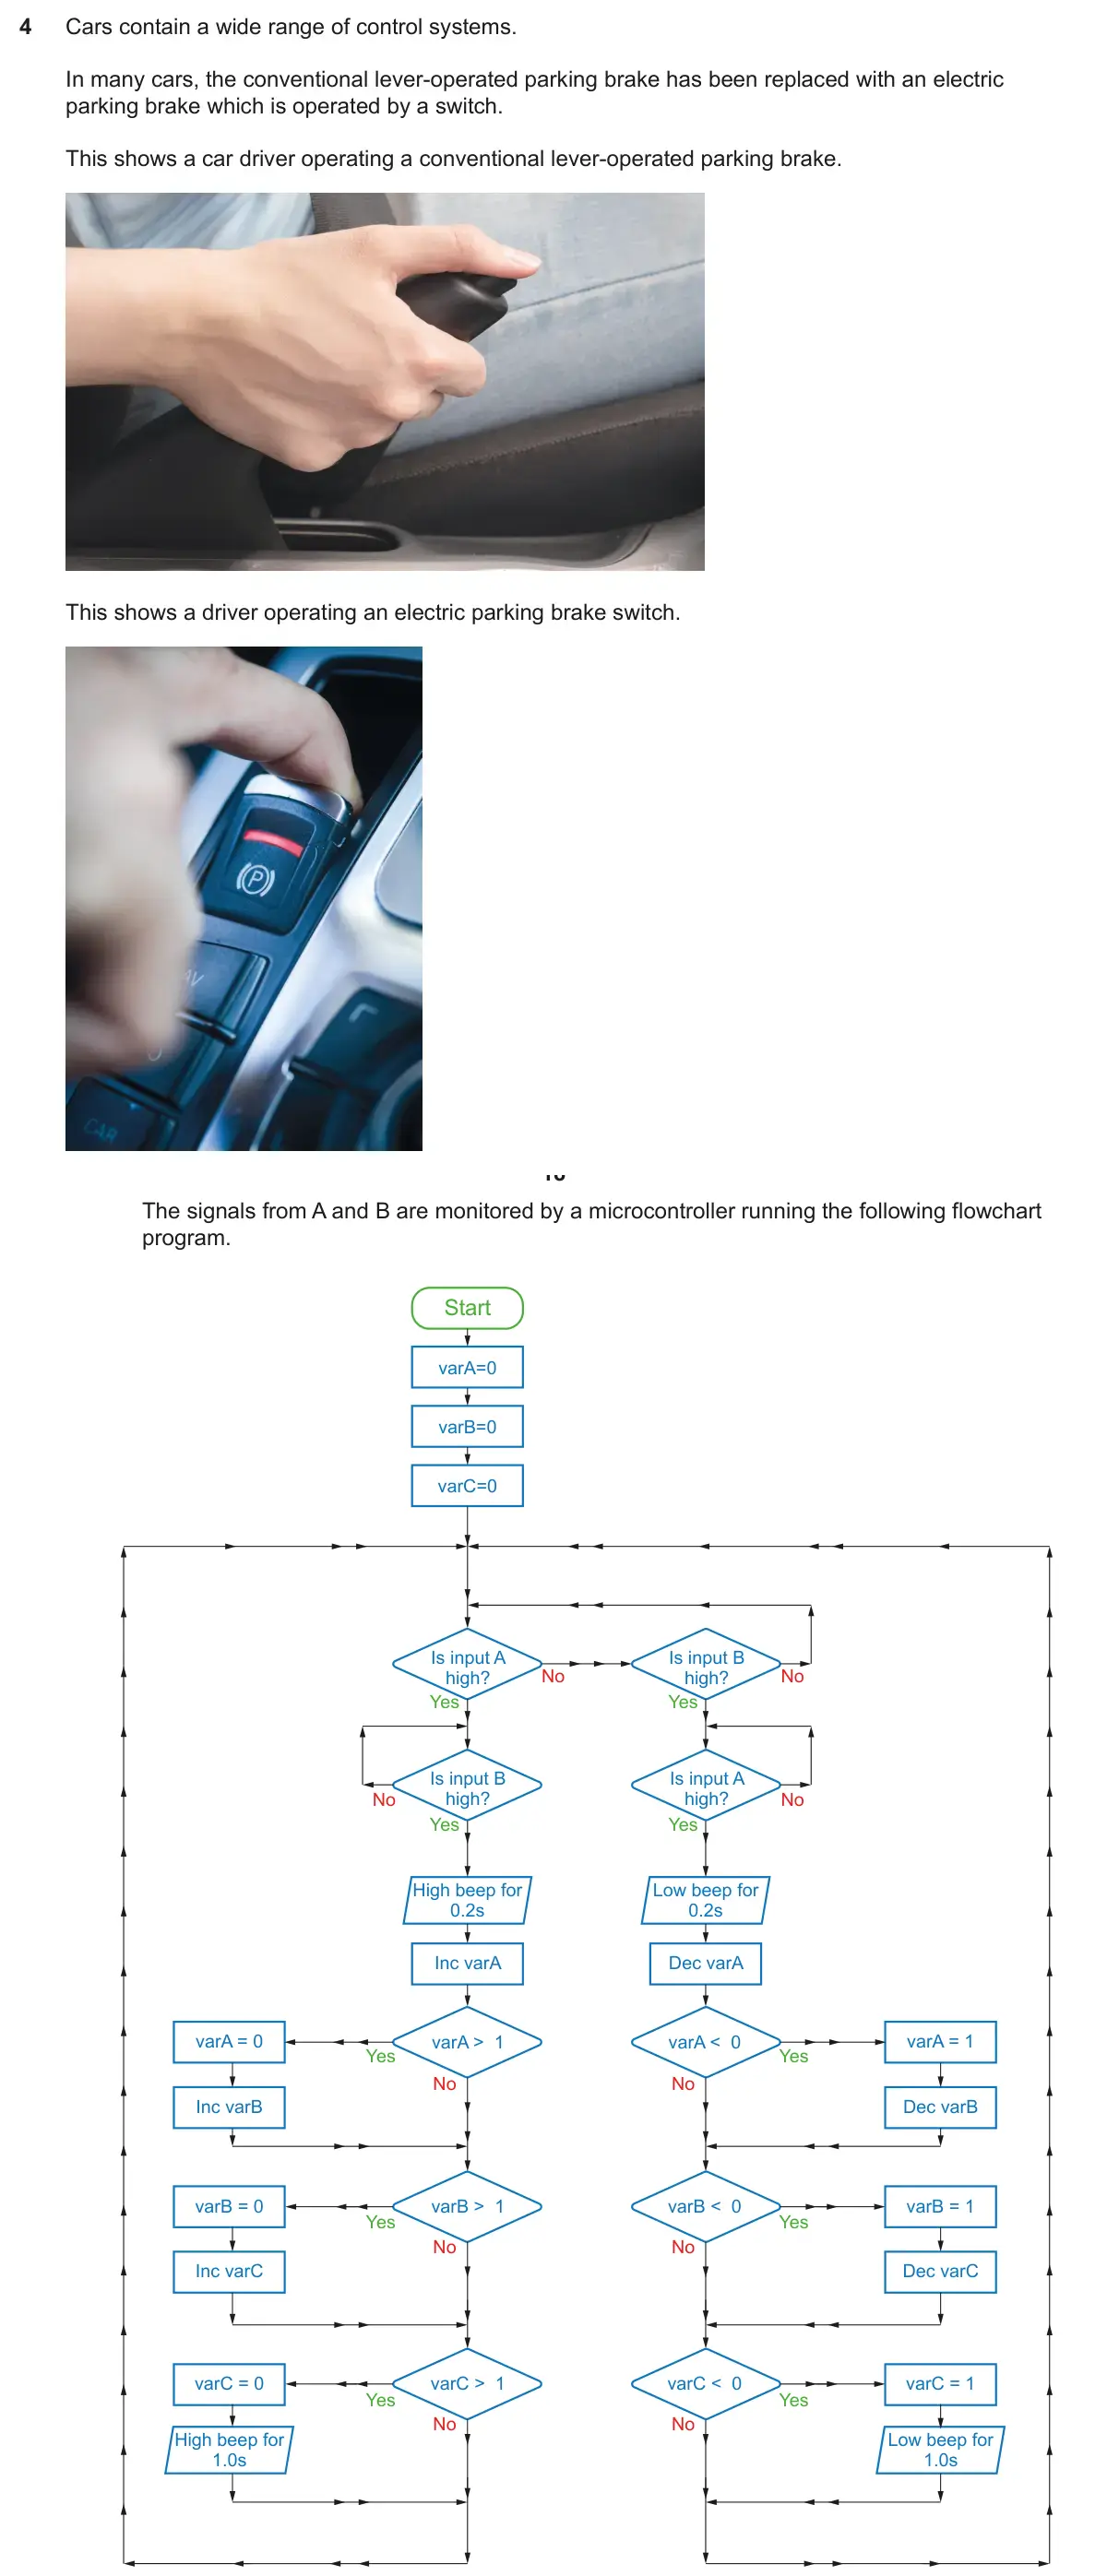
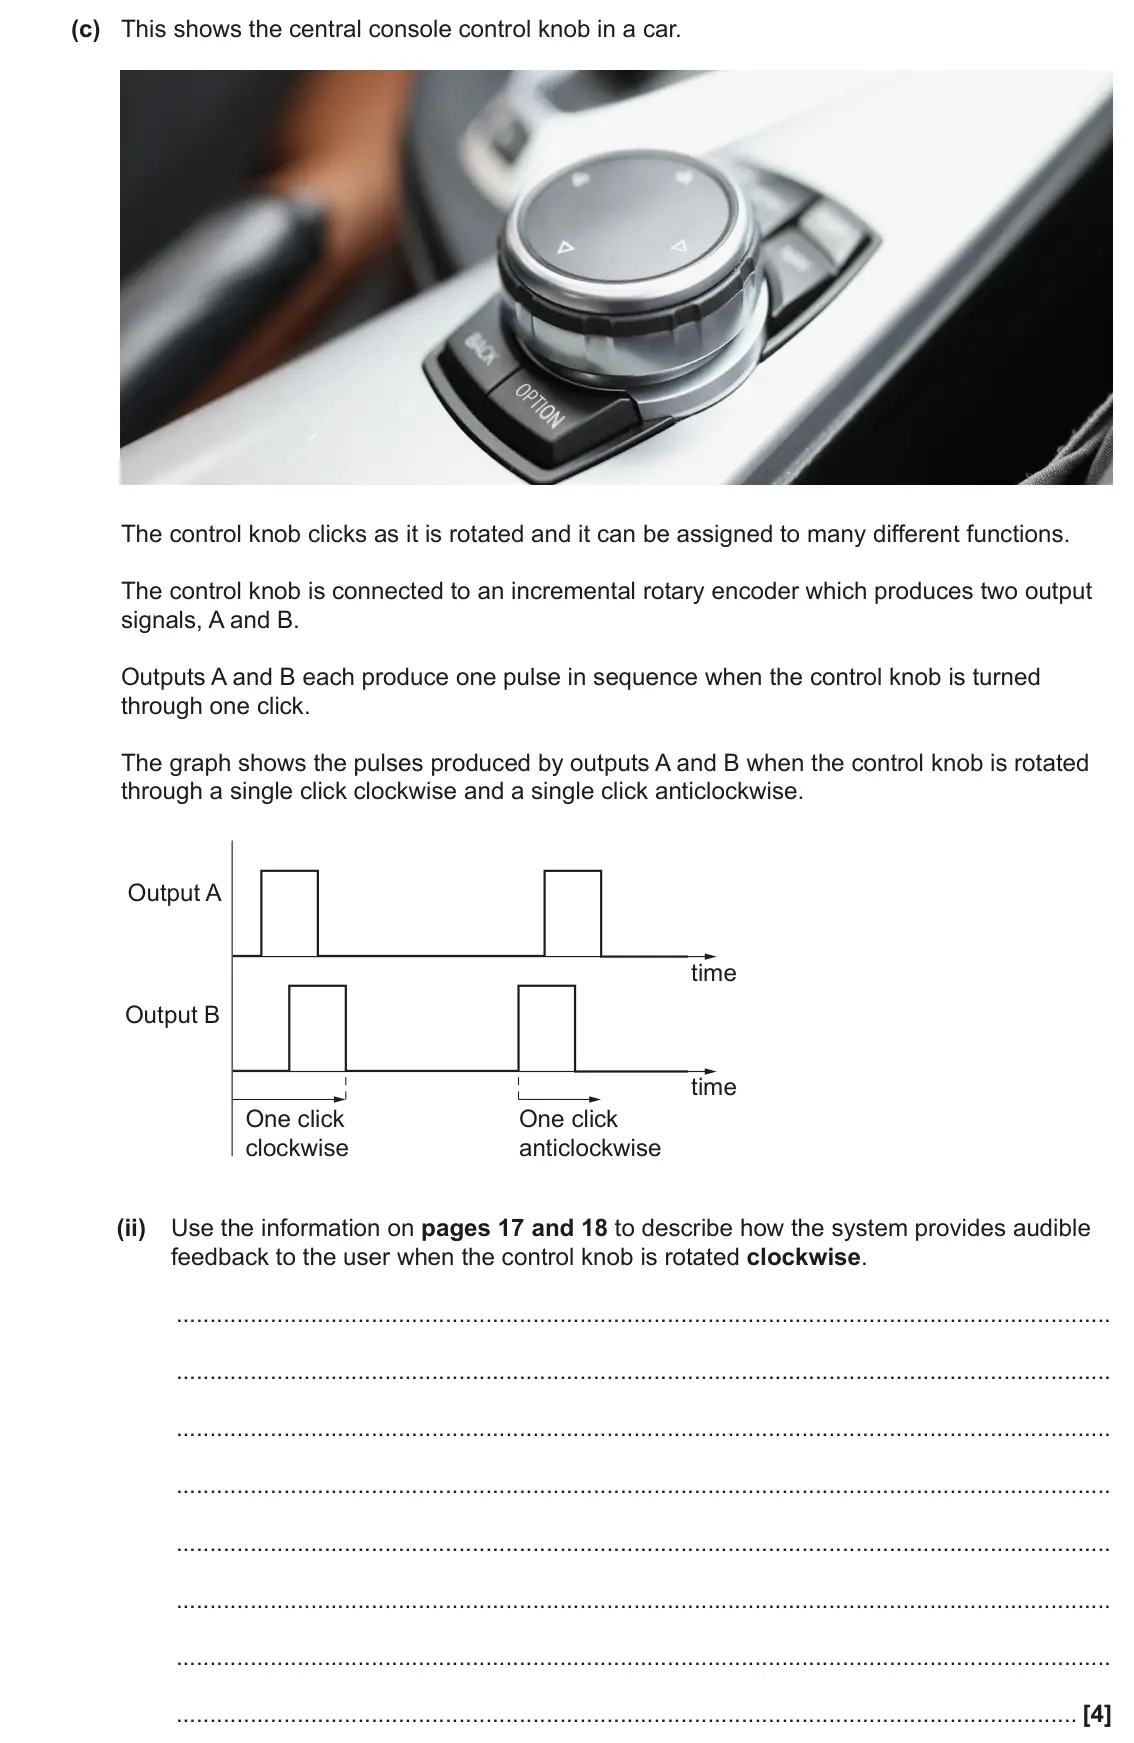
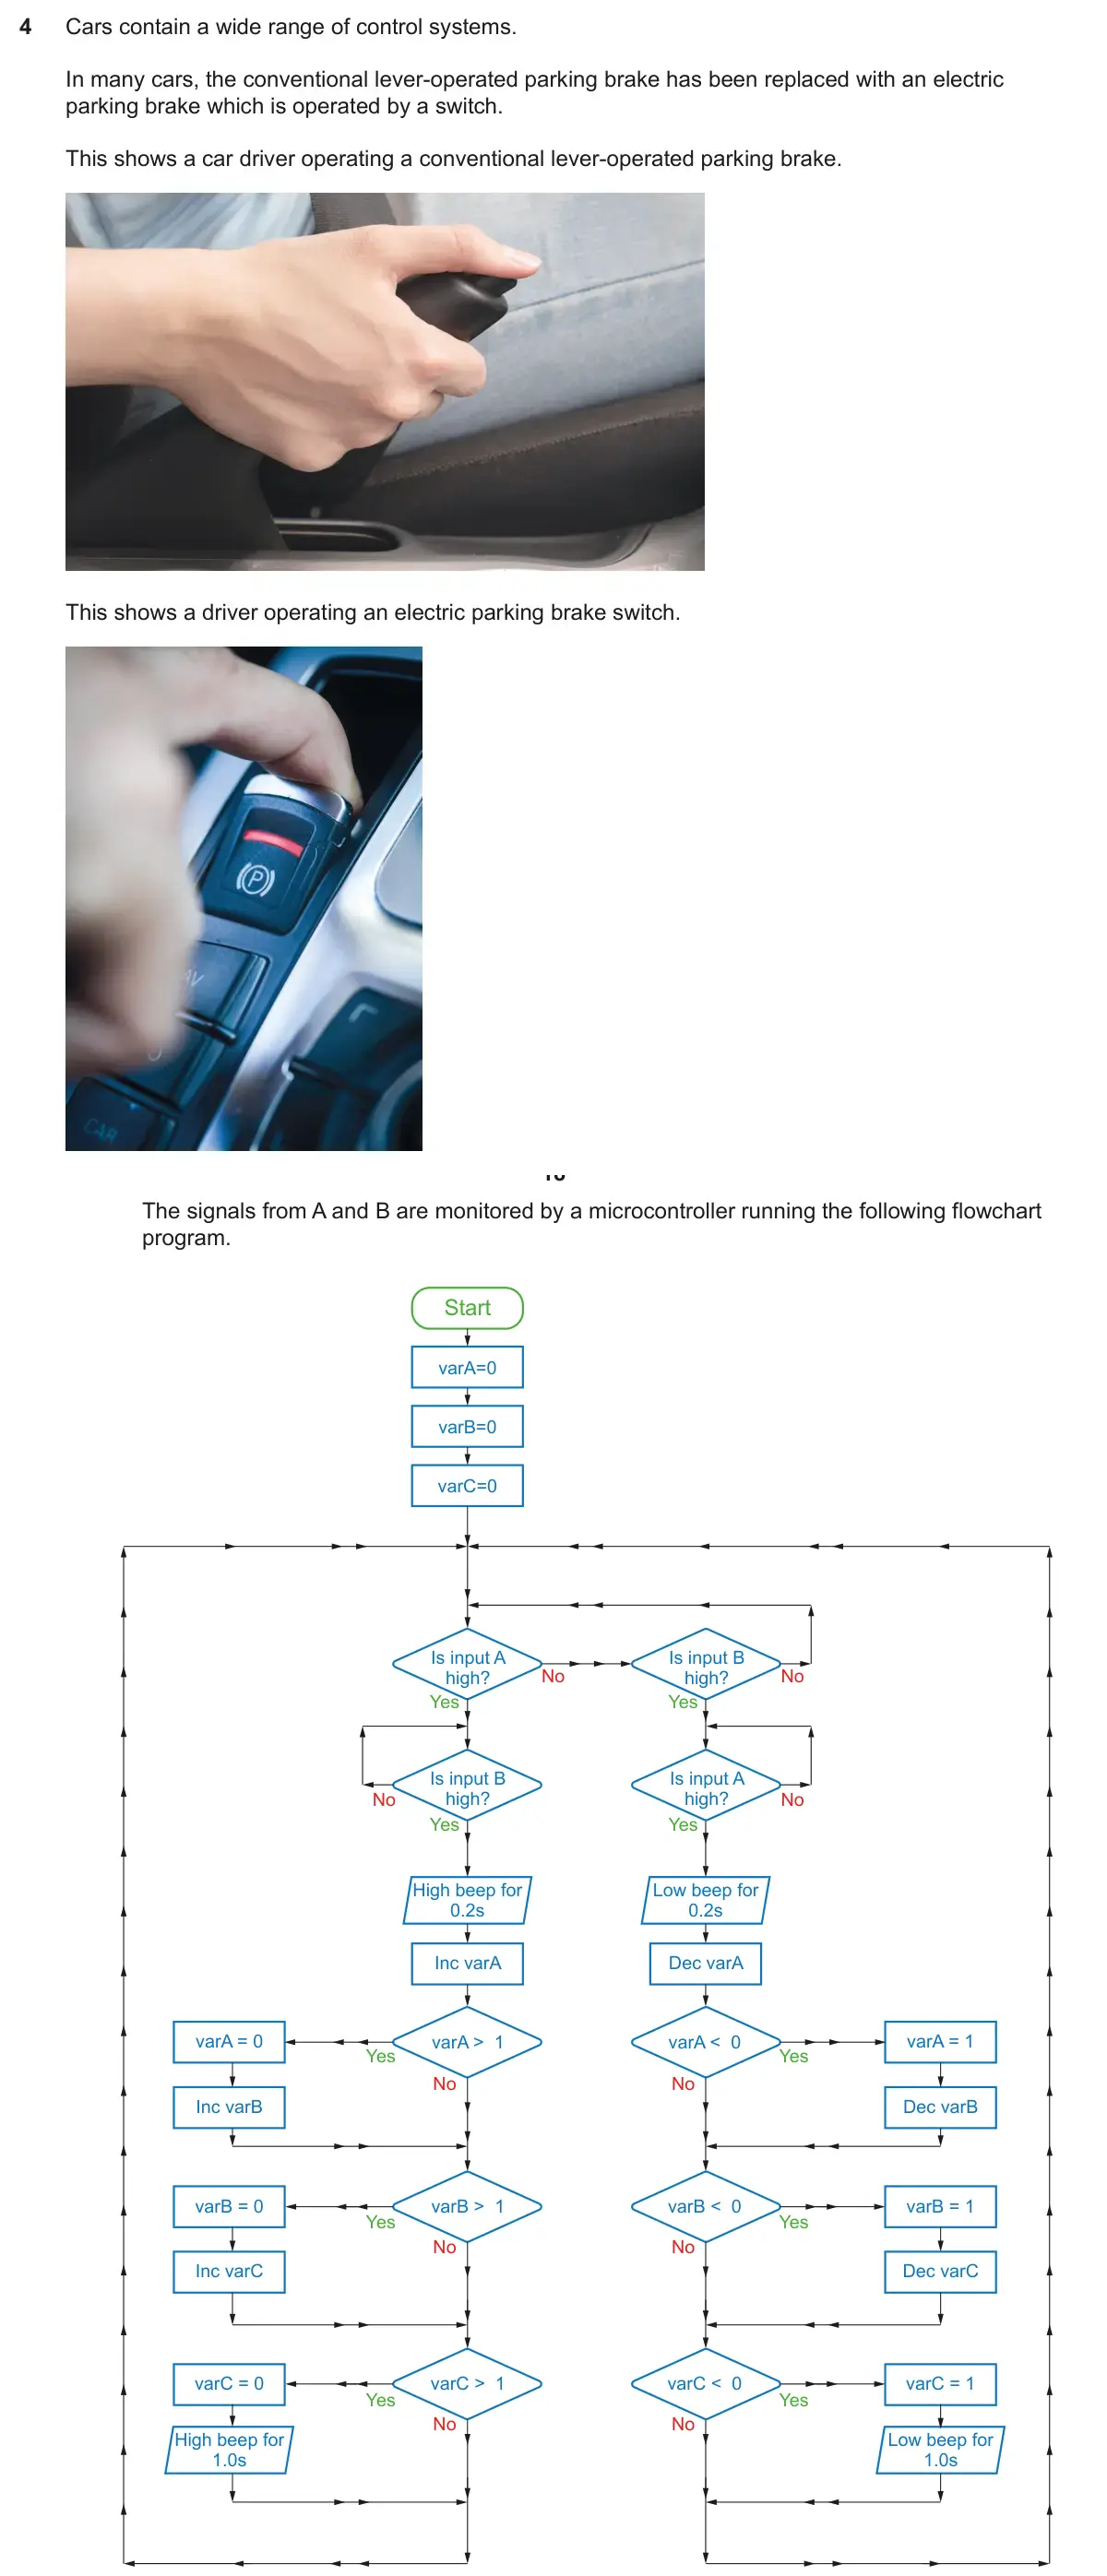
    Original question 4(c)(ii): Use the information on pages 17 and 18 to describe how the system provides audible feedback to the user when the control knob is rotated clockwise. [4]

    Loading the question…

  9. Q4(c)(iii)

    June 2023 · H404/01 · ★★

    The whole paper ↗
    9
    Setup for original question 4(c)(iii)

    Loading the question setup…

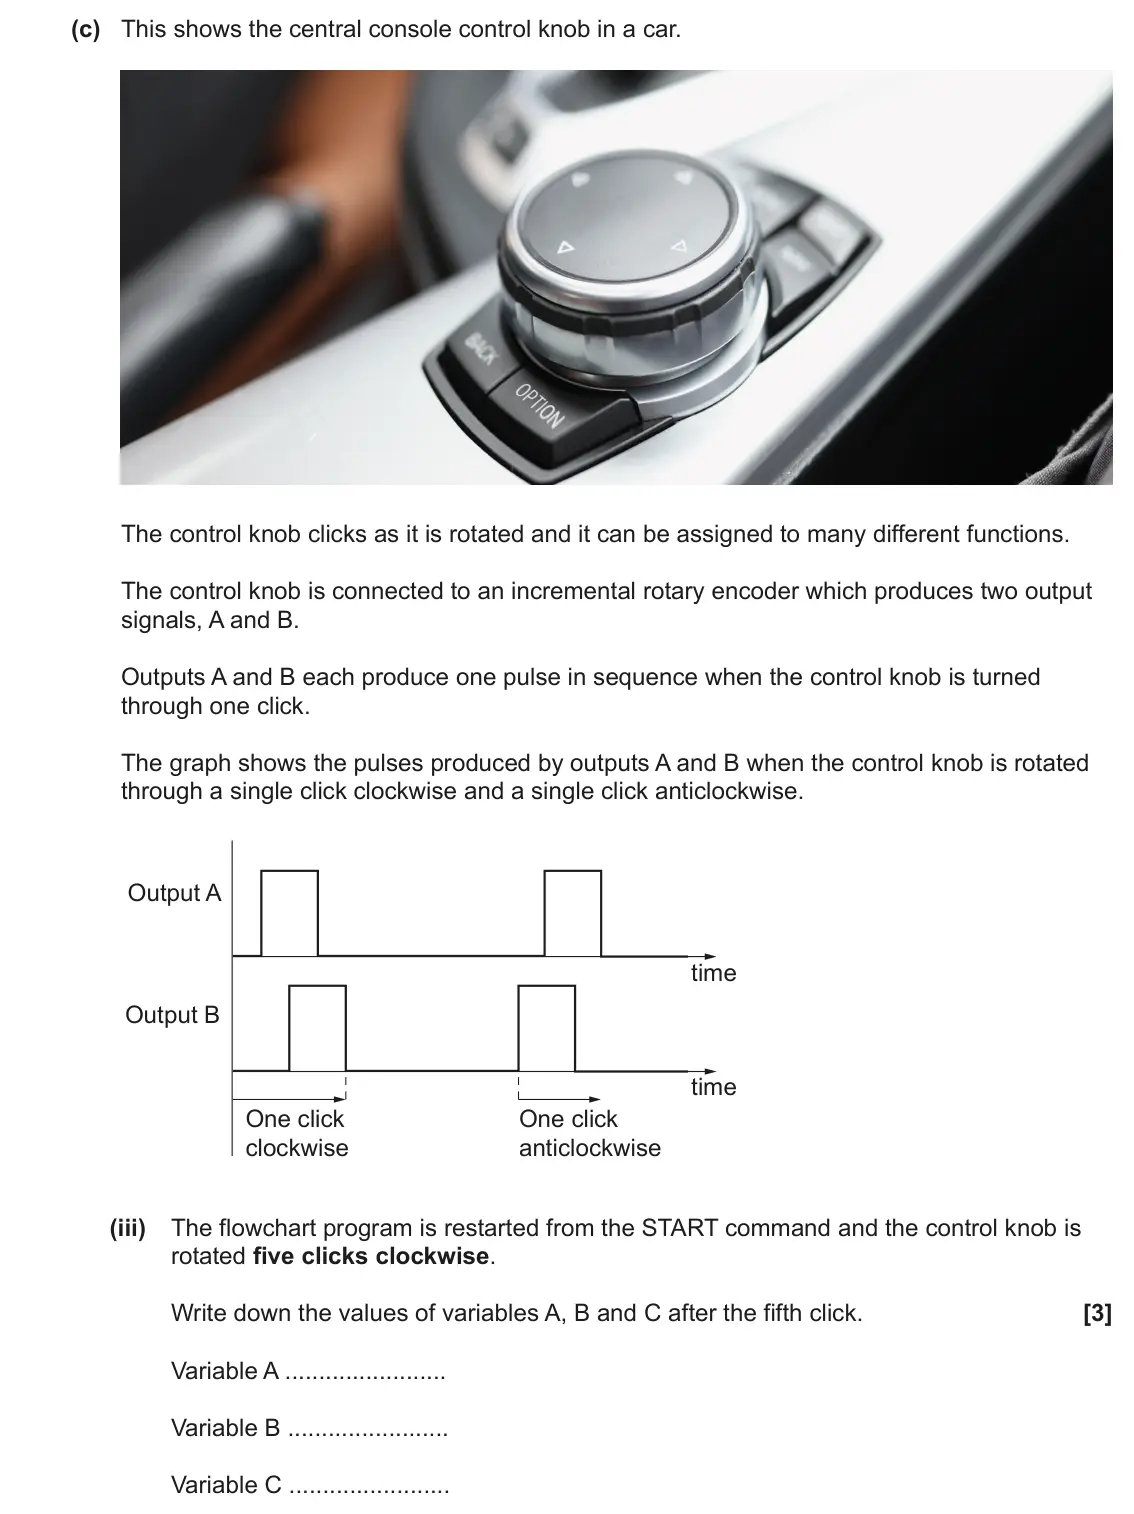
    Original question 4(c)(iii): The flowchart program is restarted from the START command and the control knob is rotated five clicks clockwise. Write down the values of variables A, B and C a

    Loading the question…

  10. Q4(c)(iv)

    June 2023 · H404/01 · ★★

    The whole paper ↗
    10
    Setup for original question 4(c)(iv)

    Loading the question setup…

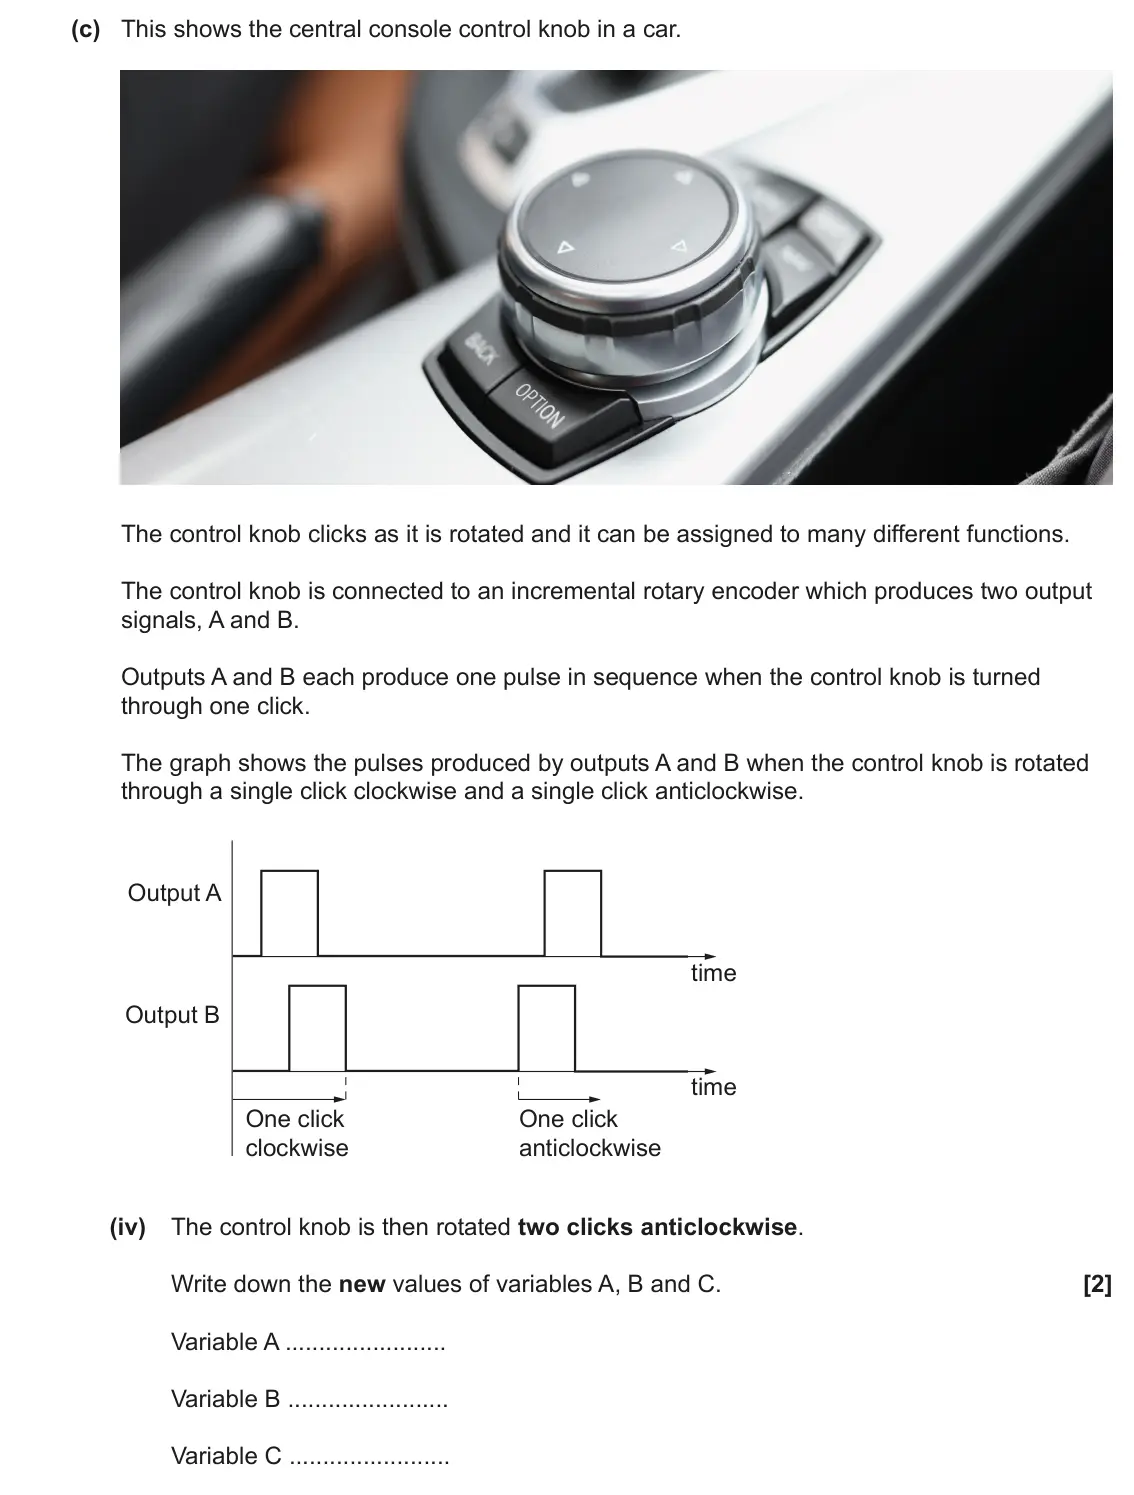
    Original question 4(c)(iv): The control knob is then rotated two clicks anticlockwise. Write down the new values of variables A, B and C. [2] Variable A Variable B Variable C

    Loading the question…

  11. Q5

    June 2023 · H404/02 · ★★★★★

    Sources (insert) ↗
    The whole paper ↗
    11
    Setup for original question 5

    Loading the question setup…

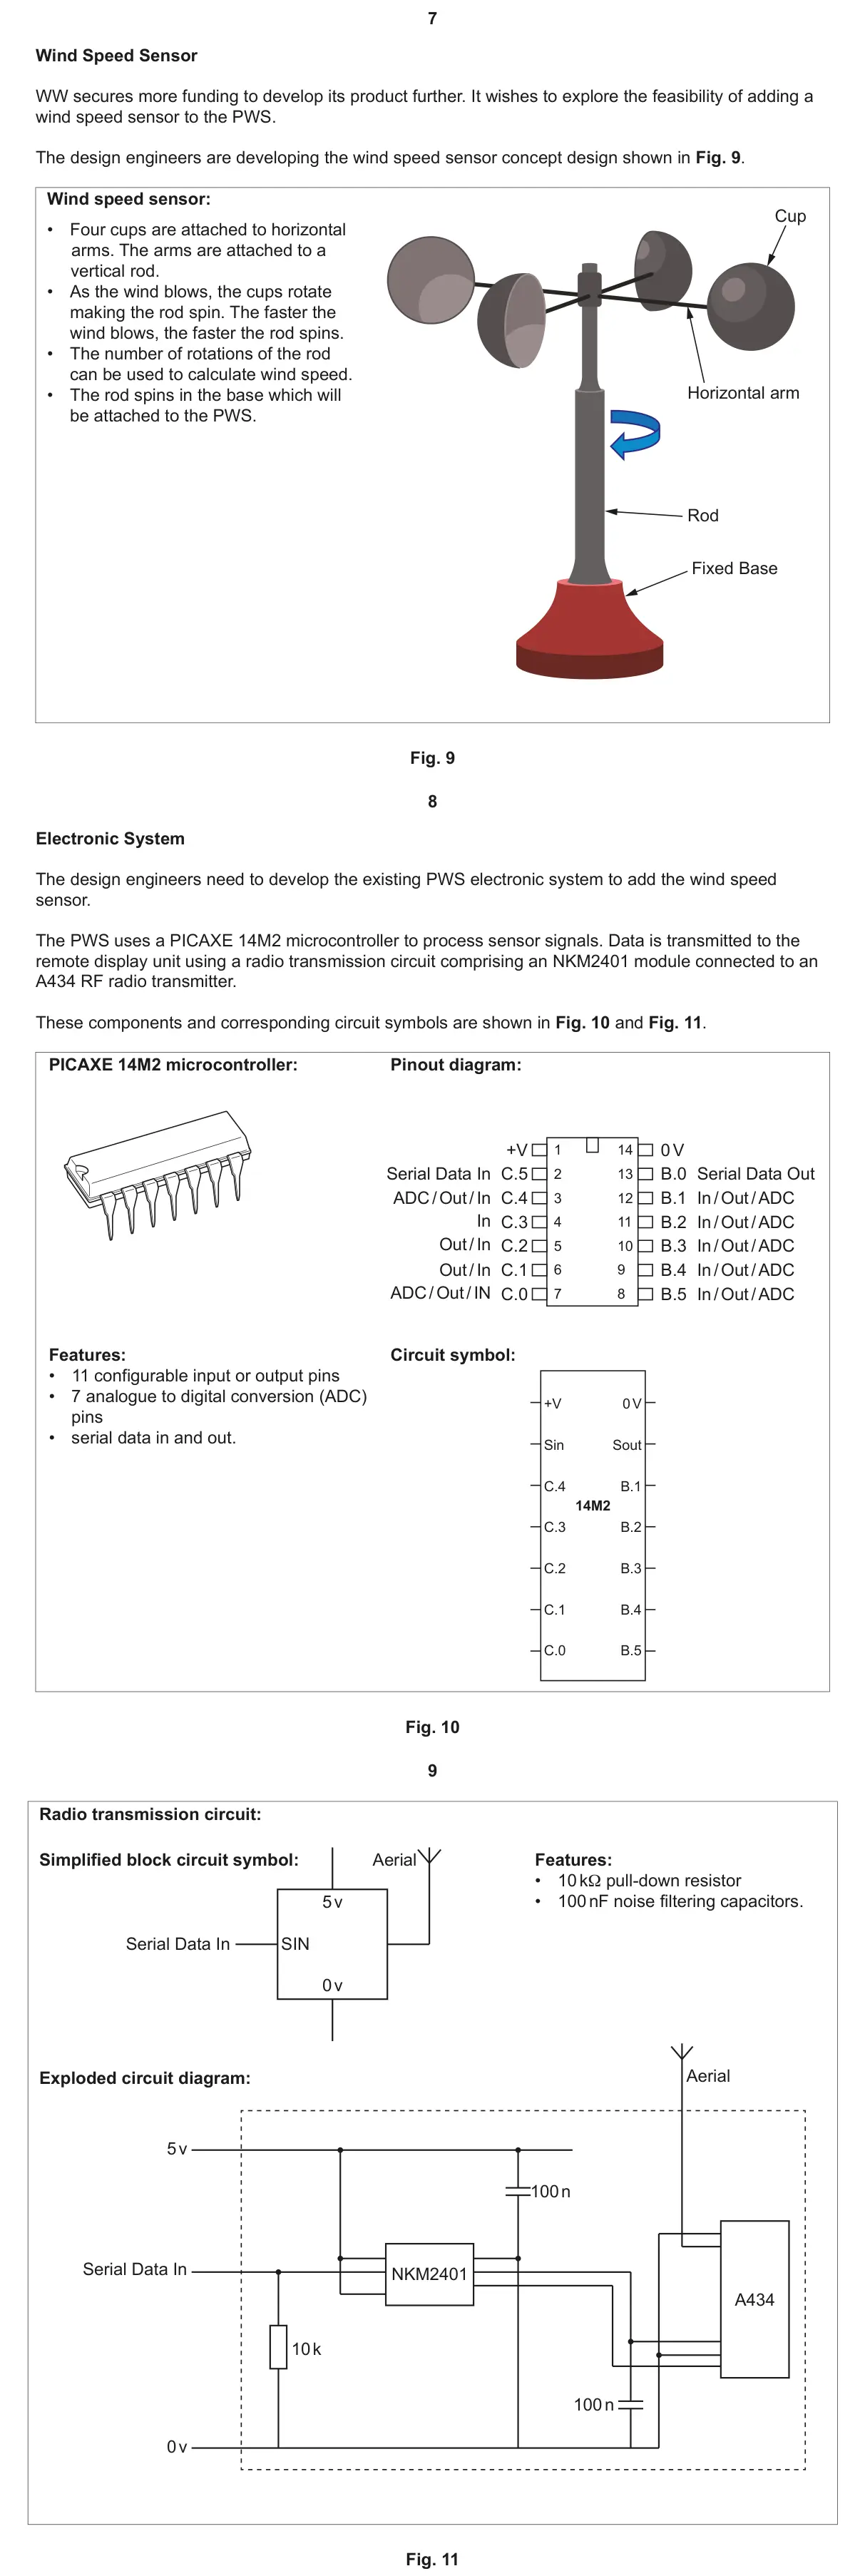
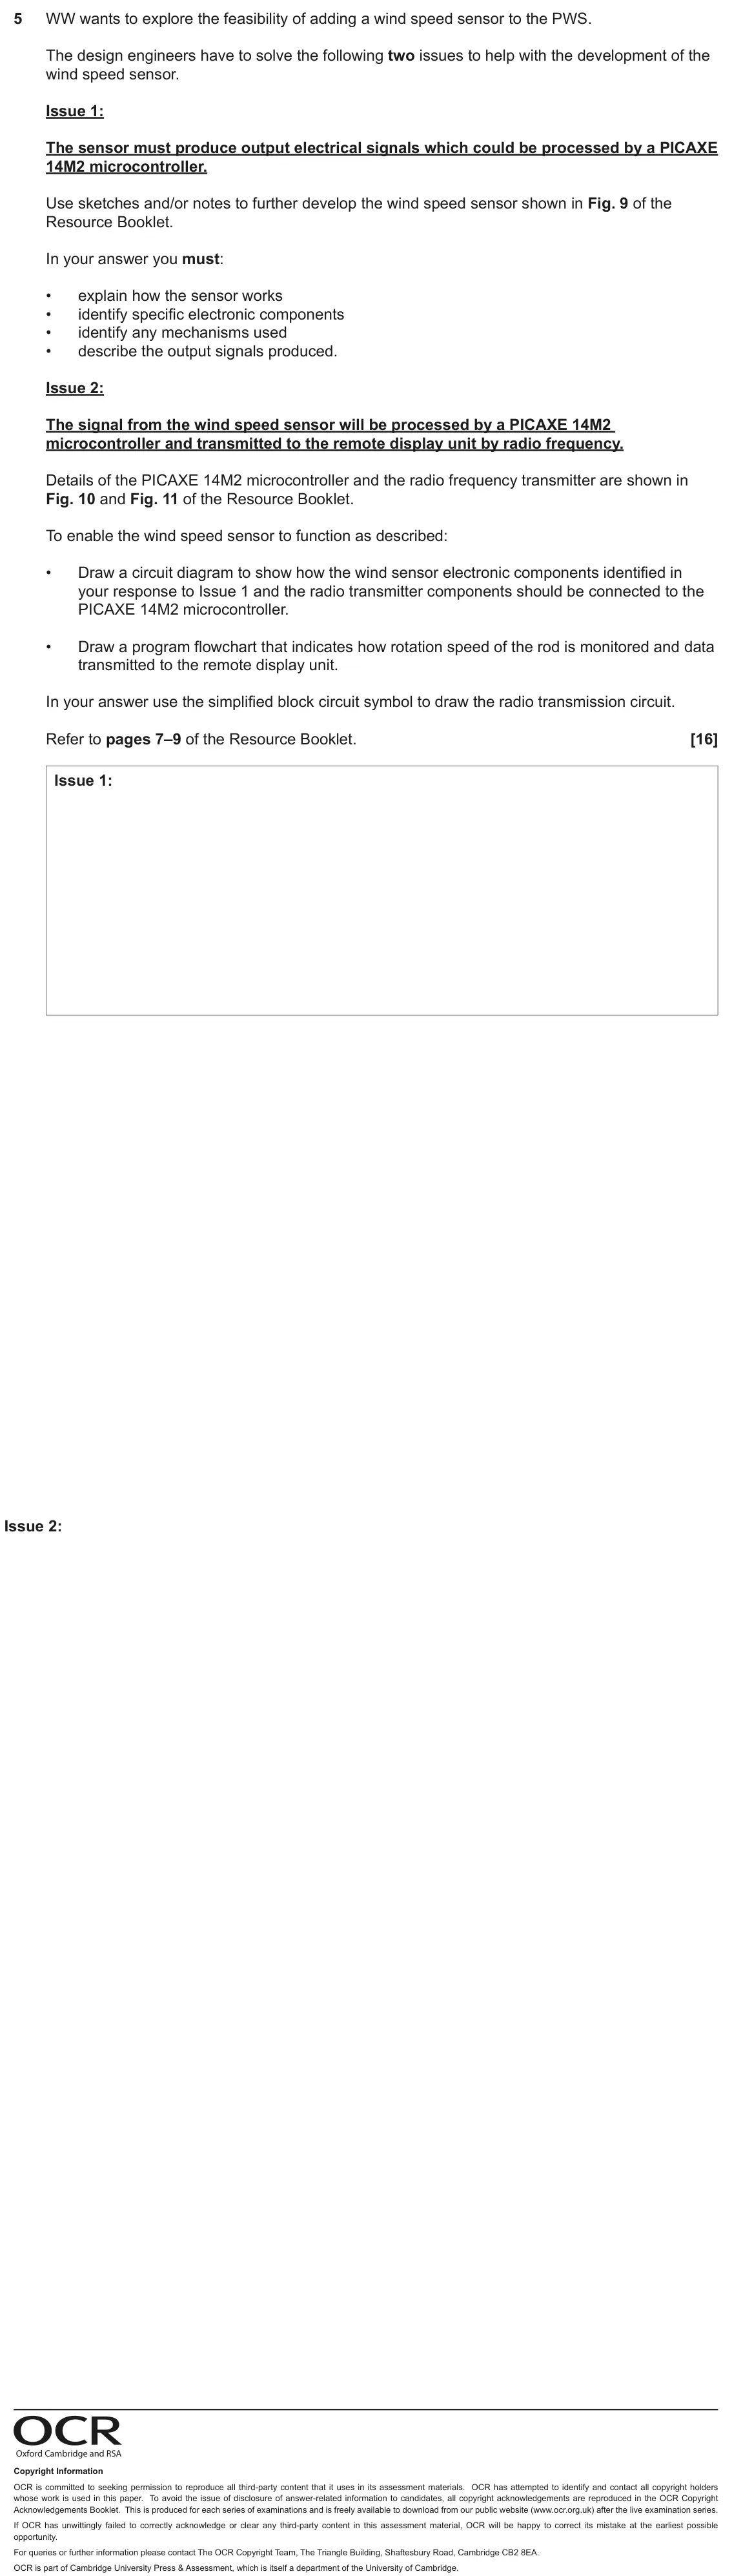
    Original question 5: WW wants to explore the feasibility of adding a wind speed sensor to the PWS. The design engineers have to solve the following two issues to help with the devel

    Loading the question…

  12. Q4

    June 2022 · H404/02 · ★★★★★

    Sources (insert) ↗
    The whole paper ↗
    12
    Setup for original question 4

    Loading the question setup…

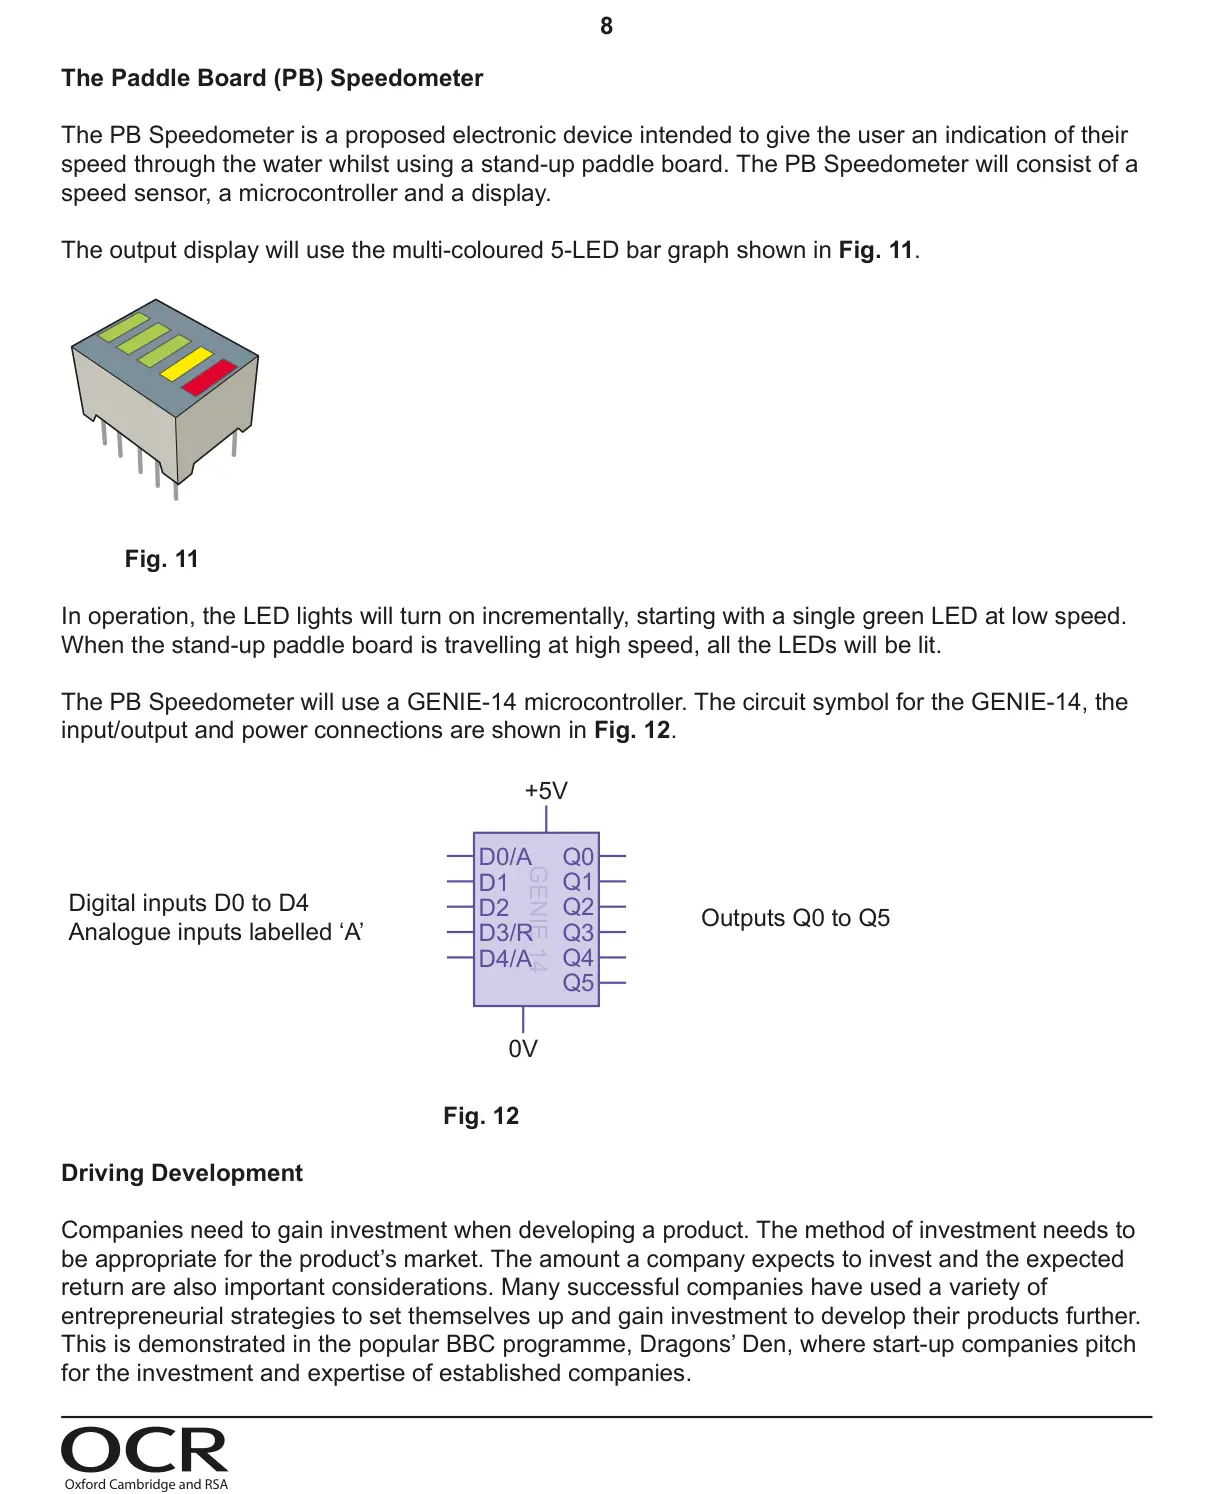
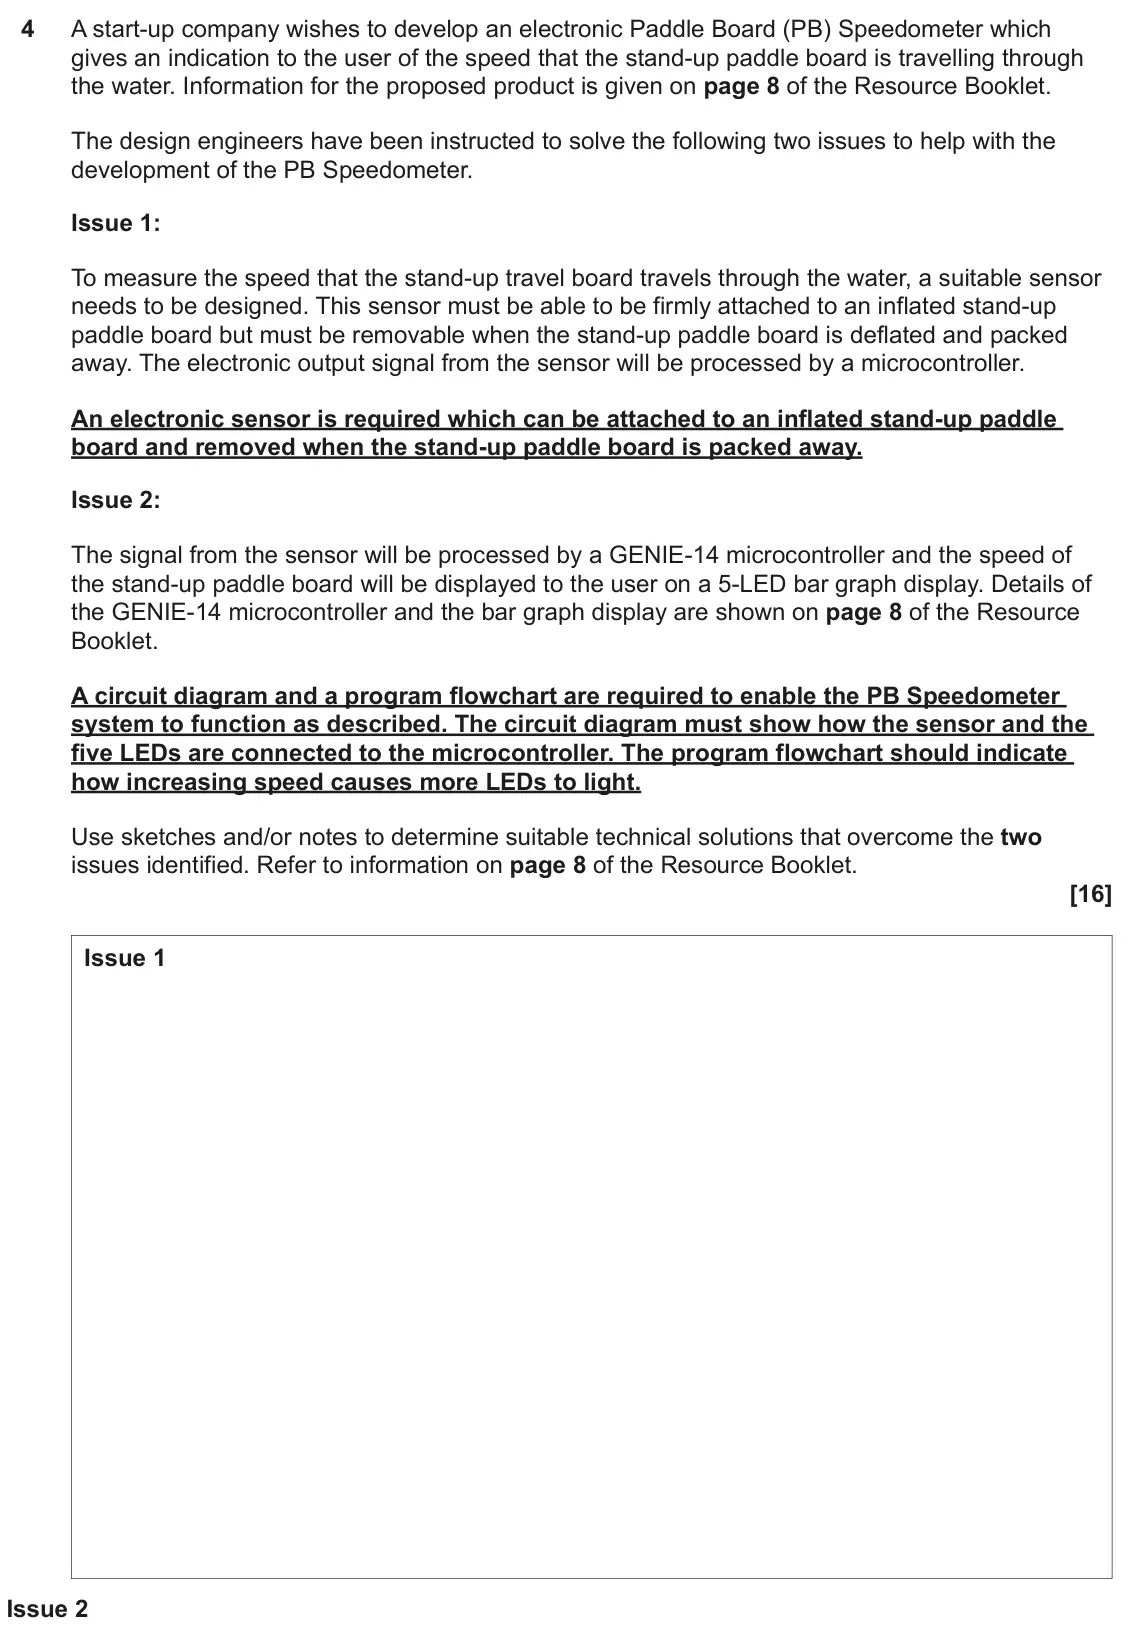
    Original question 4: A start-up company wishes to develop an electronic Paddle Board (PB) Speedometer which gives an indication to the user of the speed that the stand-up paddle boa

    Loading the question…

  13. Q3

    November 2021 · H404/02 · ★★★★★

    Sources (insert) ↗
    The whole paper ↗
    13
    Setup for original question 3

    Loading the question setup…

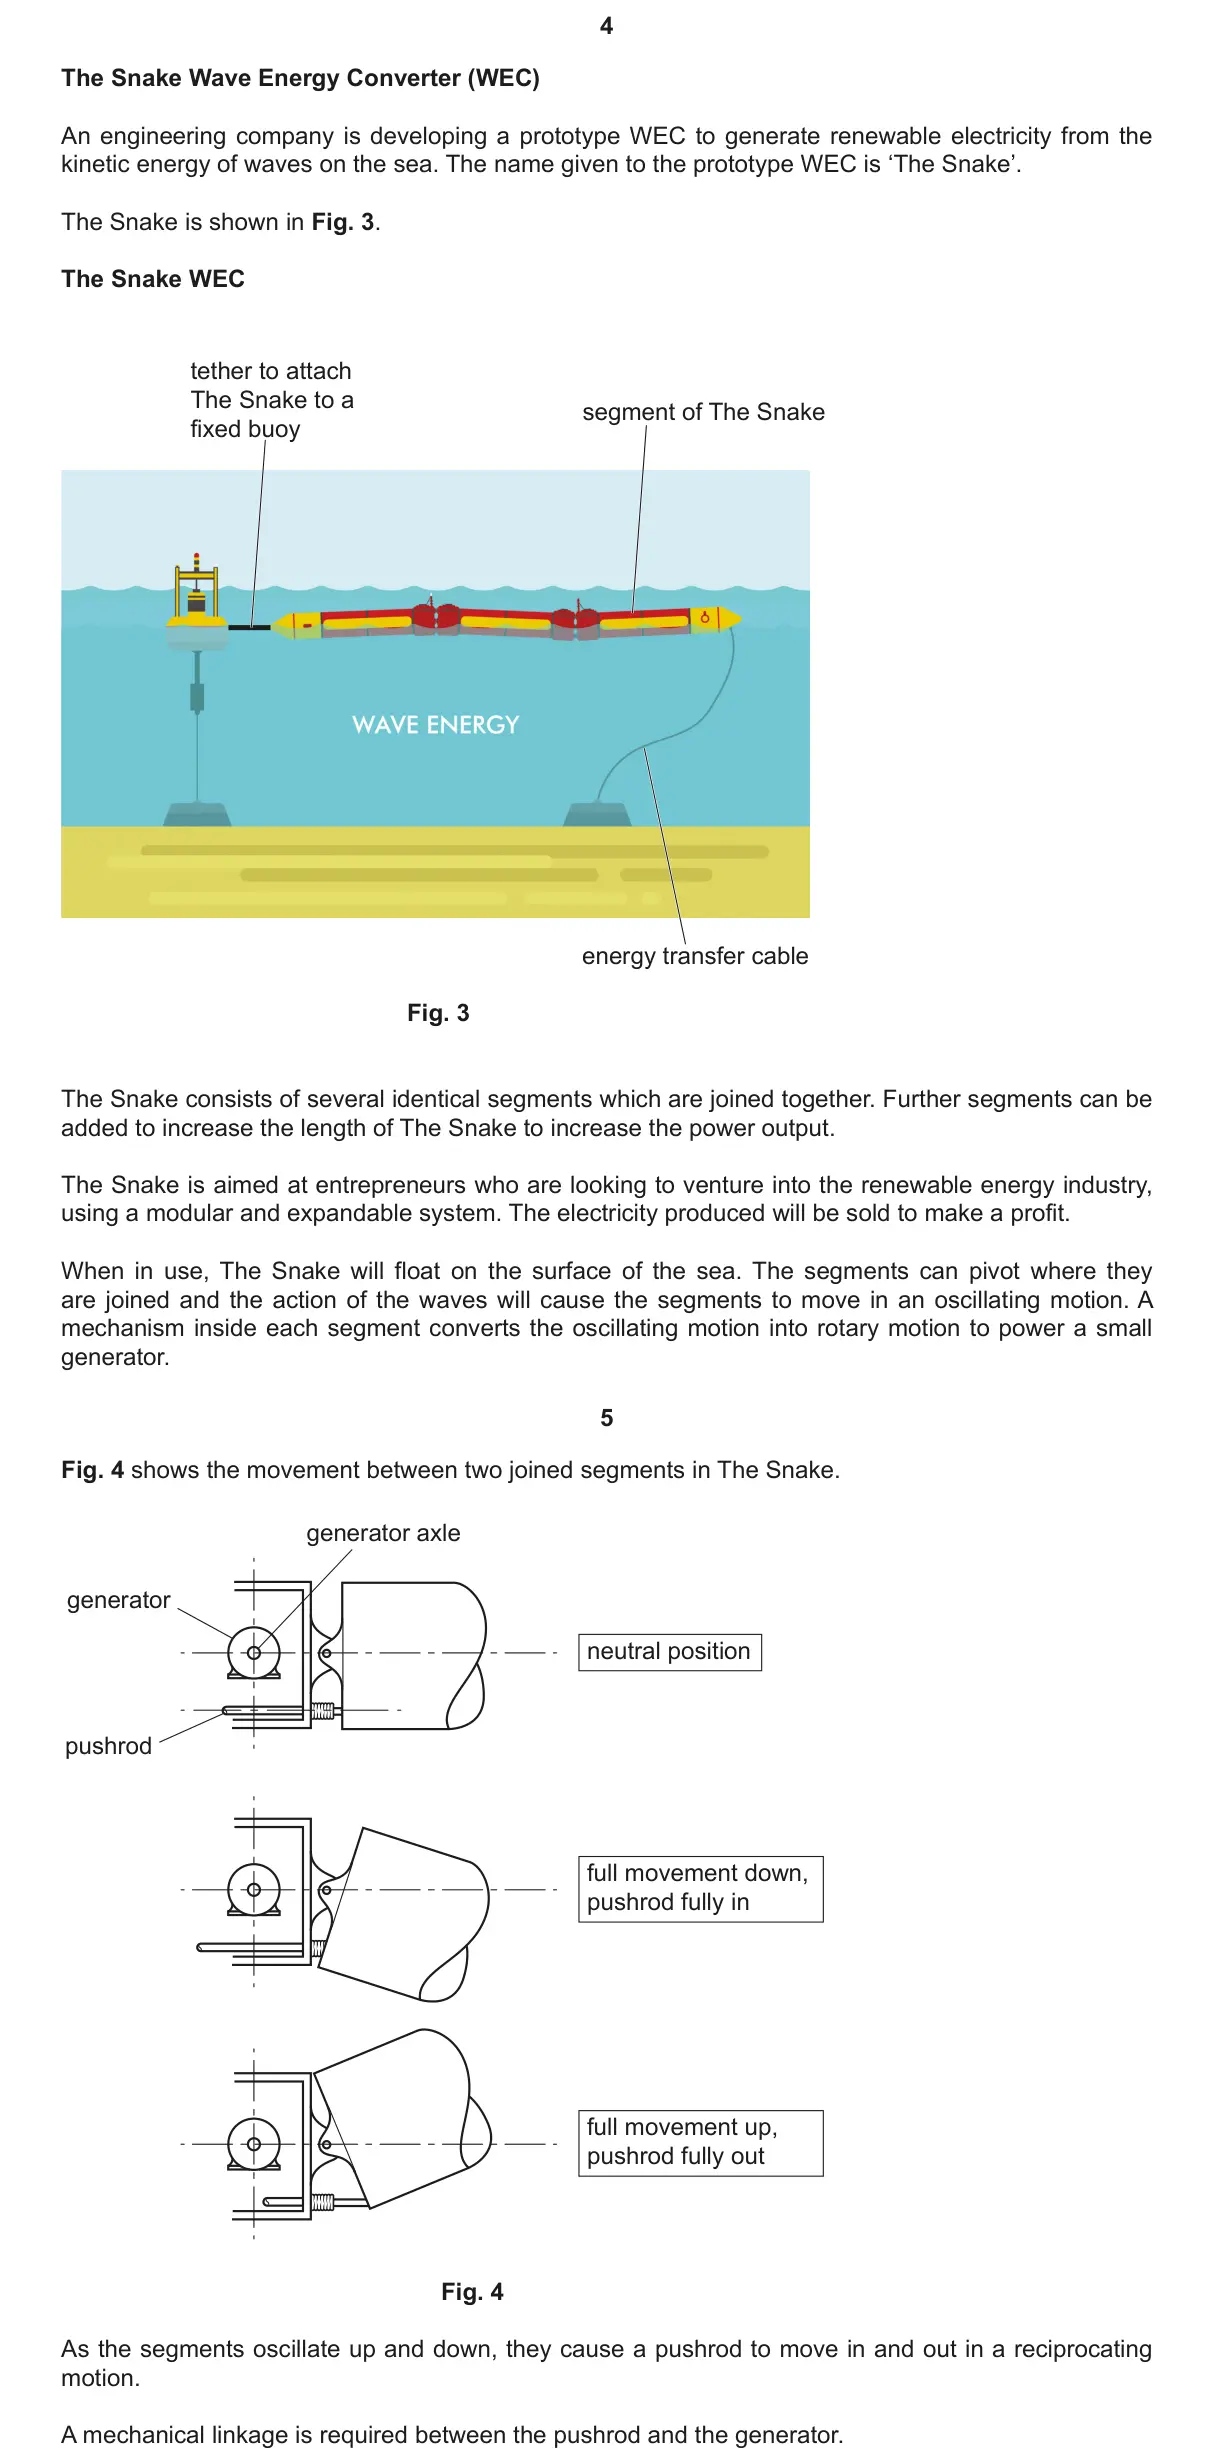
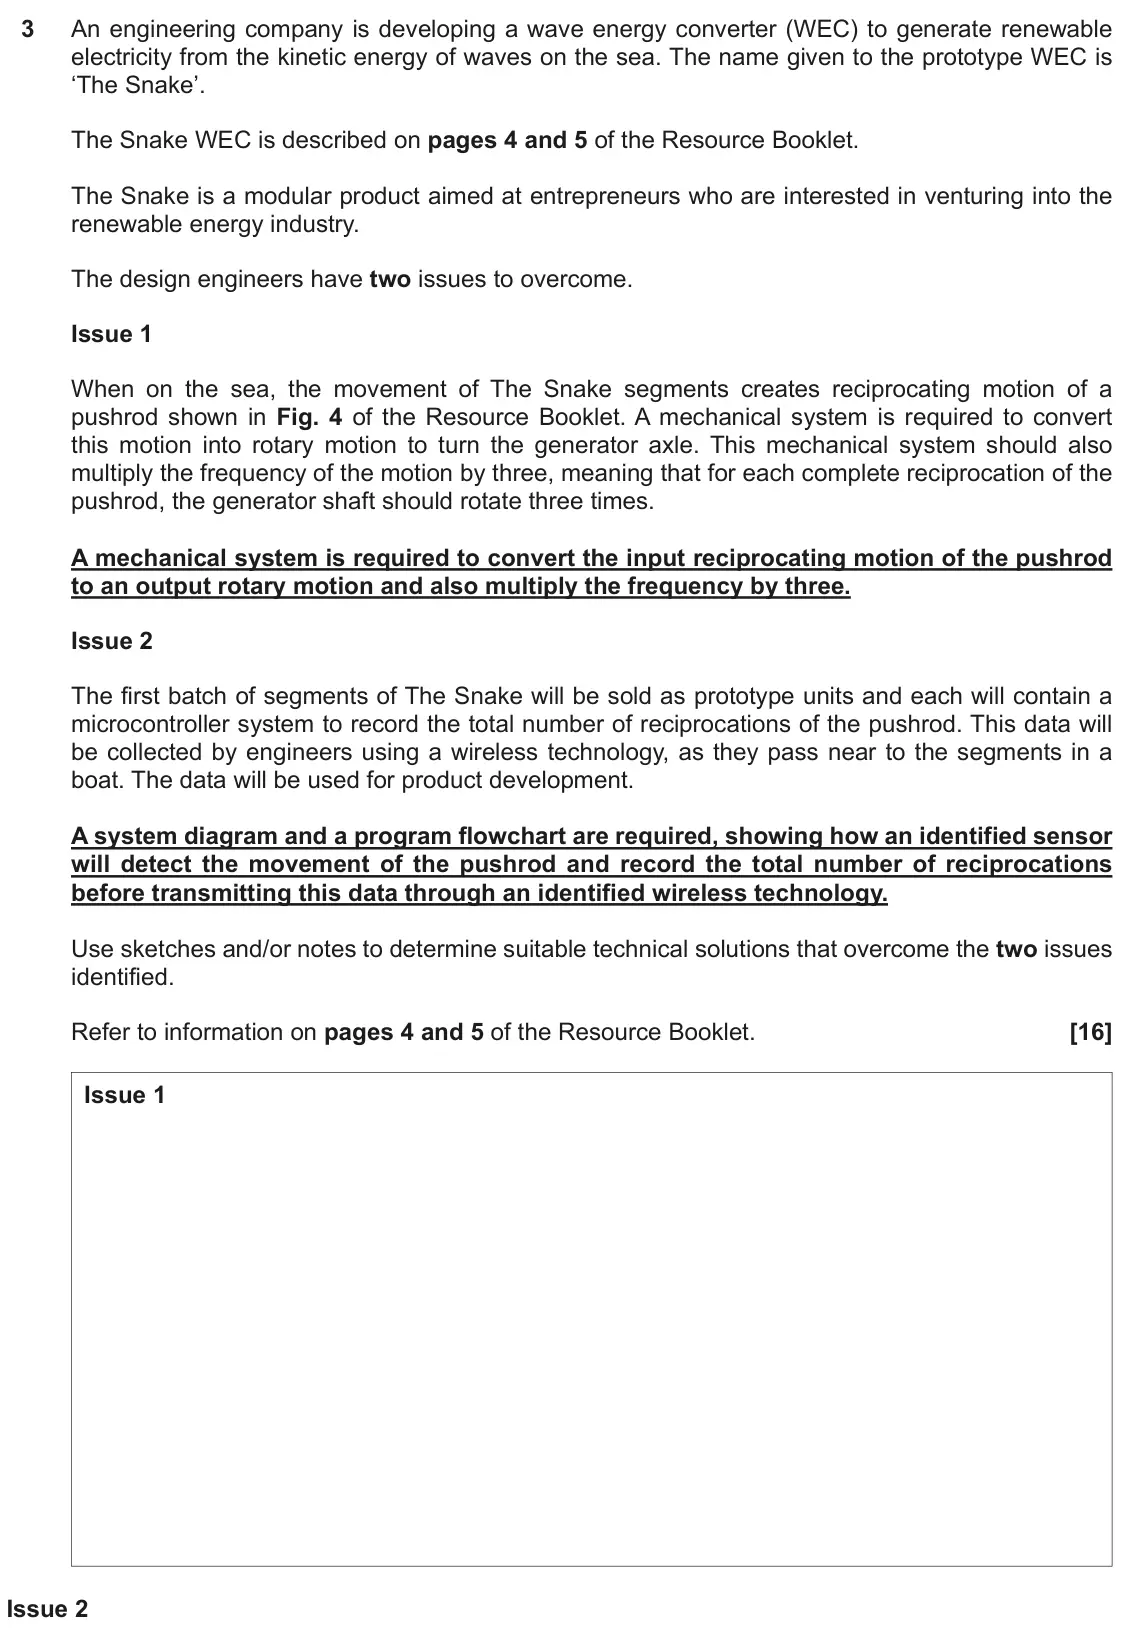
    Original question 3: An engineering company is developing a wave energy converter (WEC) to generate renewable electricity from the kinetic energy of waves on the sea. The name given

    Loading the question…

  14. Q2(c)(ii)

    Specimen · H404/01 · ★★★★

    The whole paper ↗
    14
    Setup for original question 2(c)(ii)

    Loading the question setup…

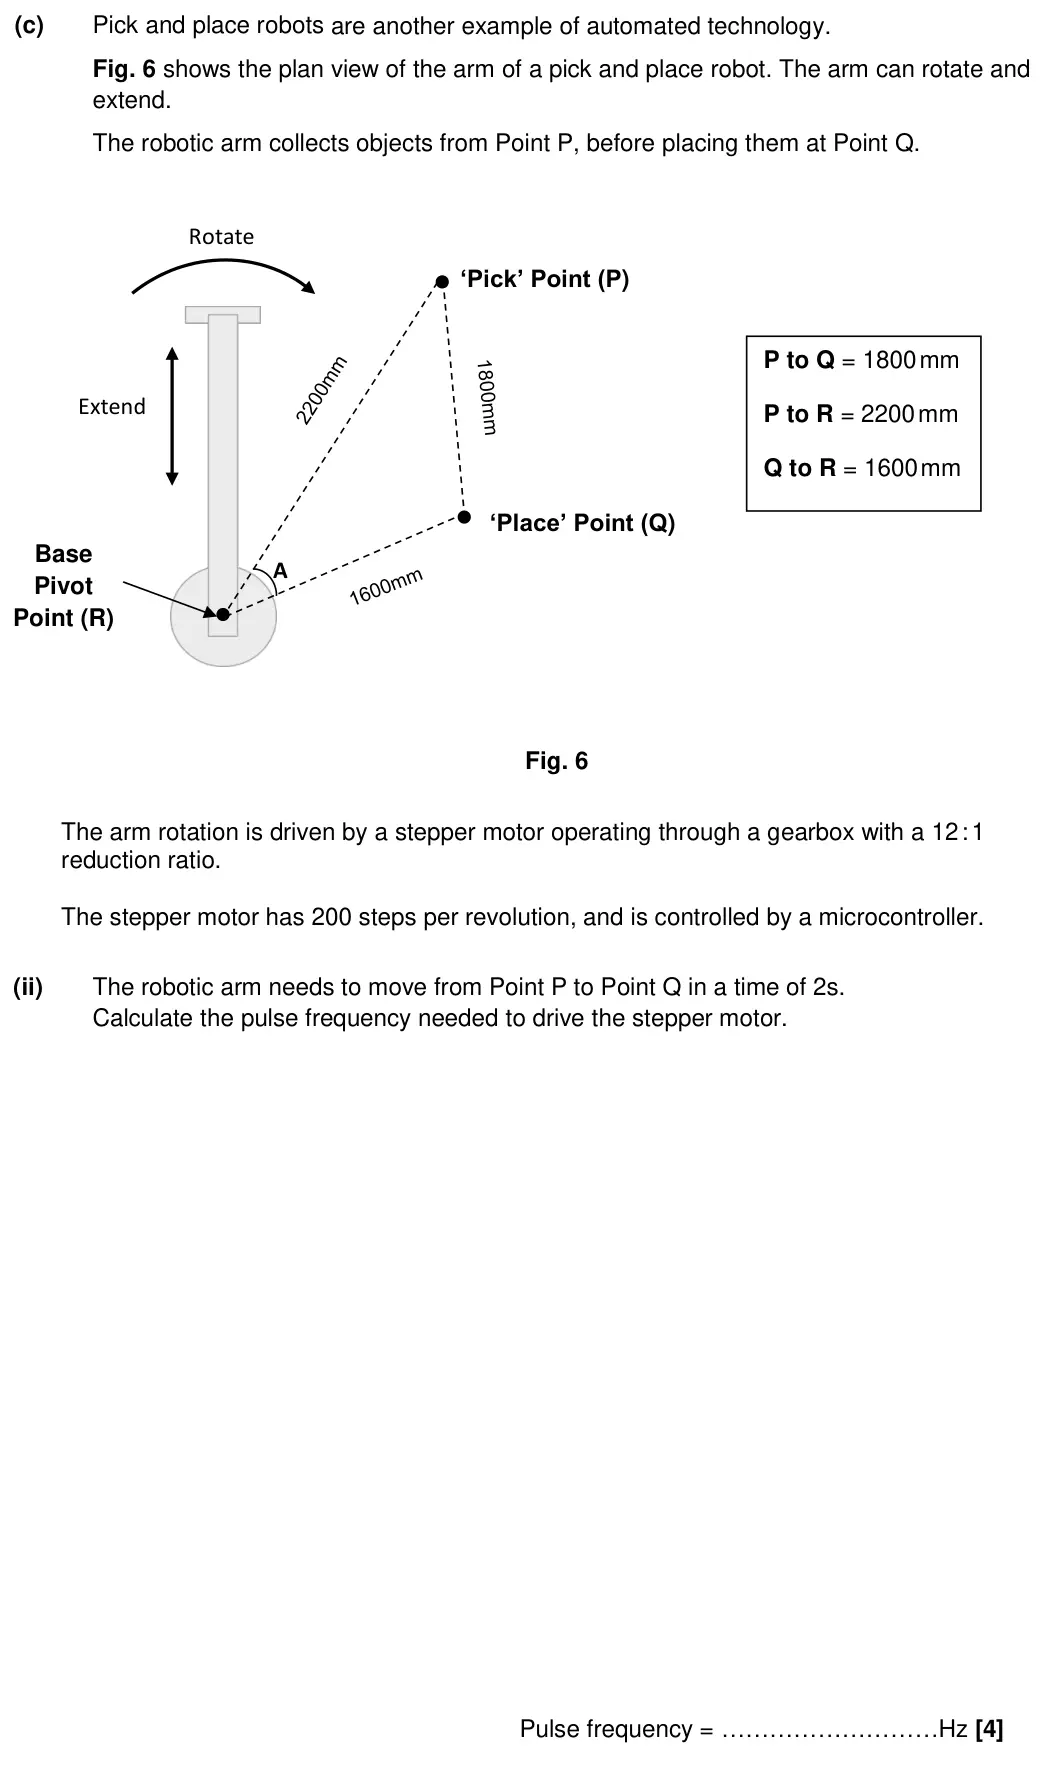
    Original question 2(c)(ii): The robotic arm needs to move from Point P to Point Q in a time of 2s. Calculate the pulse frequency needed to drive the stepper motor. Pulse frequency = Hz [4]

    Loading the question…

  15. Q2(c)(iii)

    Specimen · H404/01 · ★★

    The whole paper ↗
    15
    Setup for original question 2(c)(iii)

    Loading the question setup…

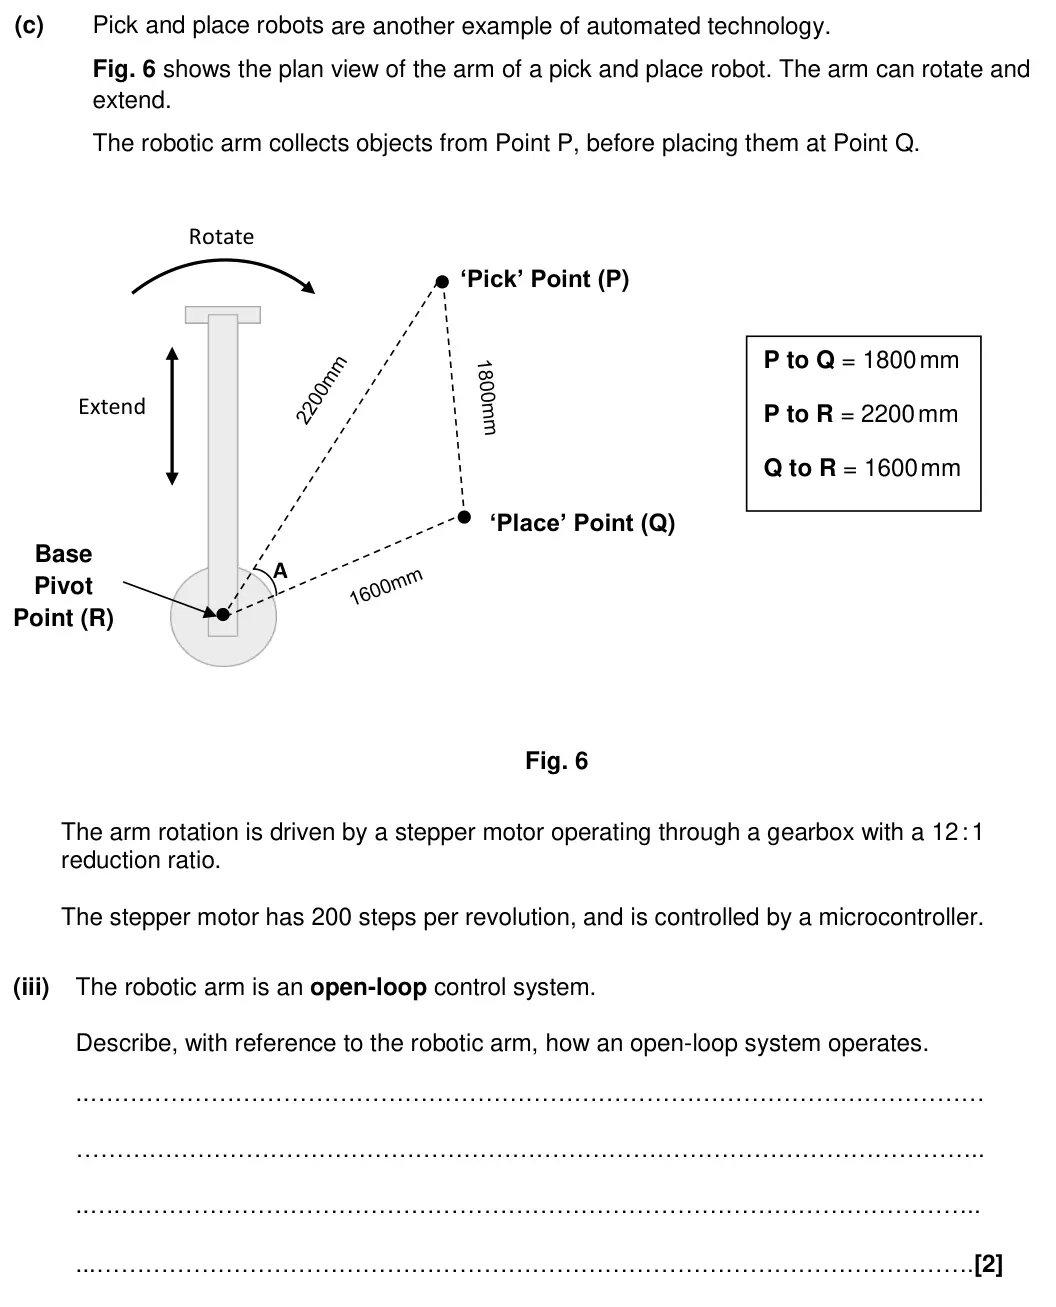
    Original question 2(c)(iii): The robotic arm is an open-loop control system. Describe, with reference to the robotic arm, how an open-loop system operates. [2]

    Loading the question…

  16. Q2(c)(iv)

    Specimen · H404/01 · ★★

    The whole paper ↗
    16
    Setup for original question 2(c)(iv)

    Loading the question setup…

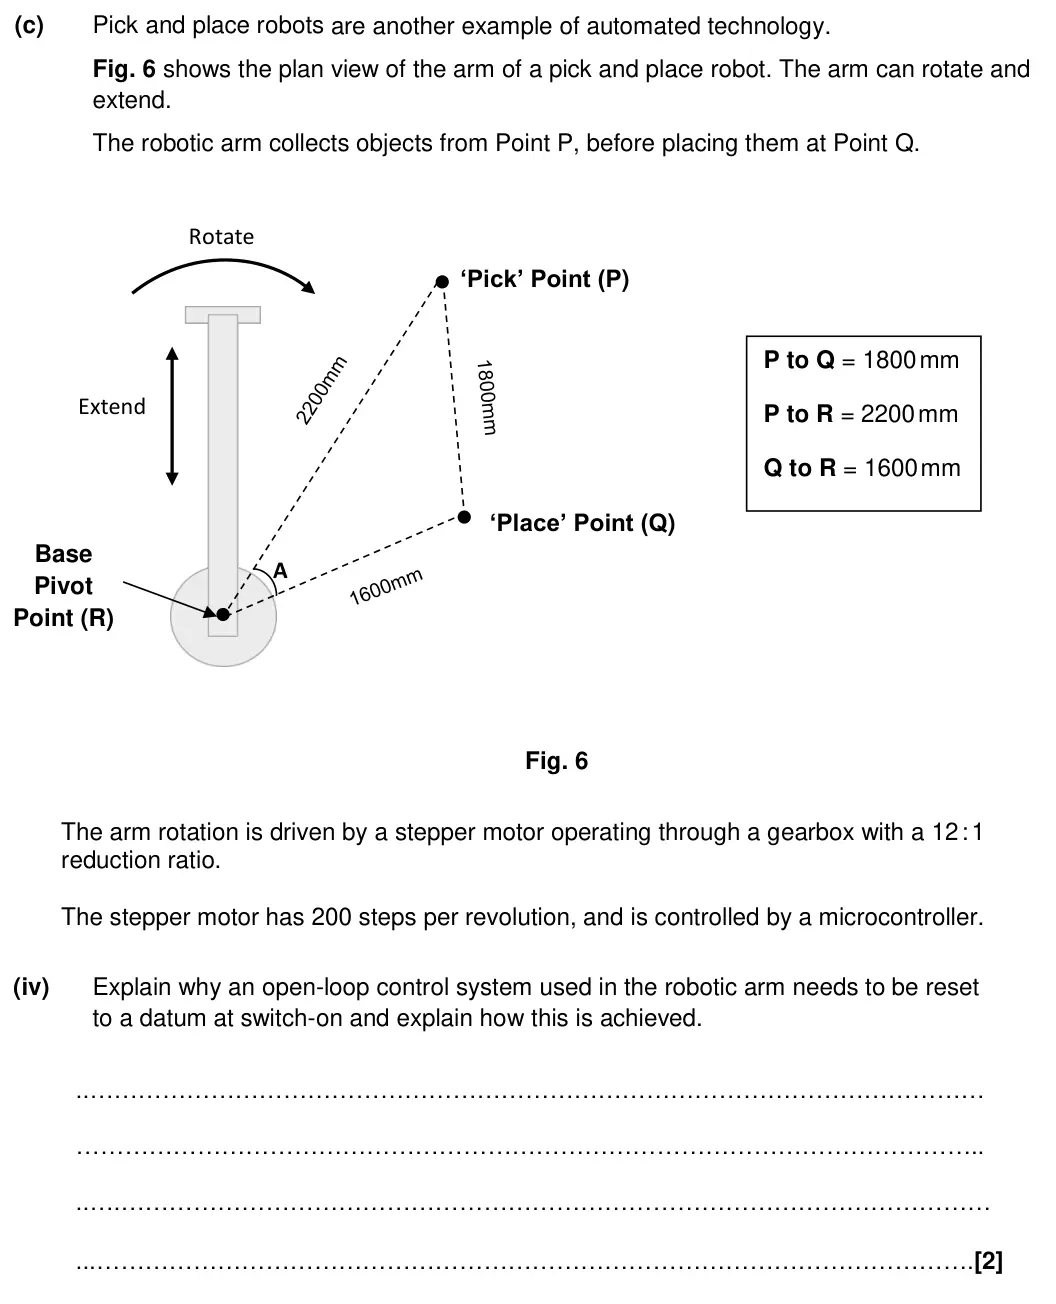
    Original question 2(c)(iv): Explain why an open-loop control system used in the robotic arm needs to be reset to a datum at switch-on and explain how this is achieved. [2]

    Loading the question…

All 16 questions on Programmable devices and control, as a list
  1. June 2025, H404/01, Q4(d) (4 marks): The manufacturer intends to develop the basic head torch. It wants the user to be able to change the brightness by repeatedly pressing the button. Fig. 4.4 show
  2. June 2025, H404/02, Q4 (16 marks): The Scout robot is equipped with a tilting fork mechanism which will help to clear small pieces of debris from its path. Details of the fork system are shown on
  3. June 2024, H404/01, Q4(c)(i) (2 marks): The paddle wheel is rotated by an electric motor in a closed loop control system. Describe how a closed loop control system achieves improved performance over a
  4. June 2024, H404/02, Q4 (16 marks): Most new play area developments are surrounded by a perimeter fence to keep children safe and to stop dogs from entering the area. The county recreation departm
  5. June 2023, H404/01, Q1(d)(v) (2 marks): Despite the increased complexity, explain one reason why a designer might choose to use a microcontroller to achieve motor speed control in products such as a p
  6. June 2023, H404/01, Q4(a) (2 marks): Explain one reason why a manufacturer might choose to install an electric parking brake rather than a lever-operated parking brake in a car. [2]
  7. June 2023, H404/01, Q4(c)(i) (3 marks): Describe how incremental rotary encoders can benefit design engineers. [3] The signals from A and B are monitored by a microcontroller running the following flo
  8. June 2023, H404/01, Q4(c)(ii) (4 marks): Use the information on pages 17 and 18 to describe how the system provides audible feedback to the user when the control knob is rotated clockwise. [4]
  9. June 2023, H404/01, Q4(c)(iii) (3 marks): The flowchart program is restarted from the START command and the control knob is rotated five clicks clockwise. Write down the values of variables A, B and C a
  10. June 2023, H404/01, Q4(c)(iv) (2 marks): The control knob is then rotated two clicks anticlockwise. Write down the new values of variables A, B and C. [2] Variable A Variable B Variable C
  11. June 2023, H404/02, Q5 (16 marks): WW wants to explore the feasibility of adding a wind speed sensor to the PWS. The design engineers have to solve the following two issues to help with the devel
  12. June 2022, H404/02, Q4 (16 marks): A start-up company wishes to develop an electronic Paddle Board (PB) Speedometer which gives an indication to the user of the speed that the stand-up paddle boa
  13. November 2021, H404/02, Q3 (16 marks): An engineering company is developing a wave energy converter (WEC) to generate renewable electricity from the kinetic energy of waves on the sea. The name given
  14. Specimen, H404/01, Q2(c)(ii) (4 marks): The robotic arm needs to move from Point P to Point Q in a time of 2s. Calculate the pulse frequency needed to drive the stepper motor. Pulse frequency = Hz [4]
  15. Specimen, H404/01, Q2(c)(iii) (2 marks): The robotic arm is an open-loop control system. Describe, with reference to the robotic arm, how an open-loop system operates. [2]
  16. Specimen, H404/01, Q2(c)(iv) (2 marks): Explain why an open-loop control system used in the robotic arm needs to be reset to a datum at switch-on and explain how this is achieved. [2]

Questions, mark schemes and examiner’s reports are © OCR, from their published past papers. Plumi isn’t affiliated with any exam board. Want whole papers? OCR A-Level Design Engineering past papers.

The Plumi iPad app also offers exam-style questions with AI feedback on your handwritten working.